@article{bayesian-probabilistic-data-association,
  title = {BPDA-GMM: Bayesian Probabilistic Data Association via Gaussian Mixture Models for Semantic SLAM},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Antonio Sgorbissa and Nak Young Chong},
  journal = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Journal2026
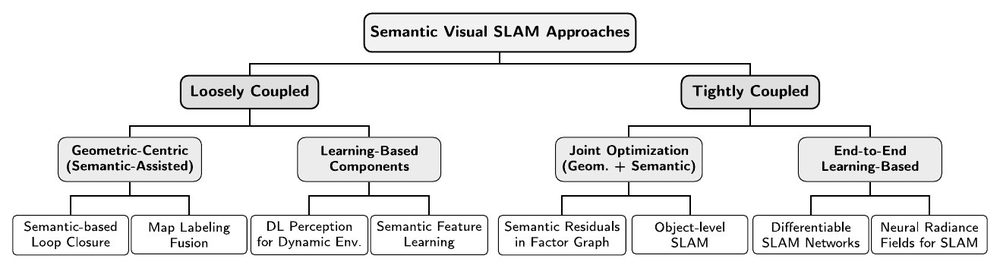
Semantic Visual Simultaneous Localization and Mapping: A survey on state of the art,
challenges, and future directions
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
@article{semantic-visual-slam-survey,
  title = {Semantic Visual Simultaneous Localization and Mapping: A survey on state of the art, challenges, and future directions},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  journal = {Robotics and Autonomous Systems},
  year = {2026}
}
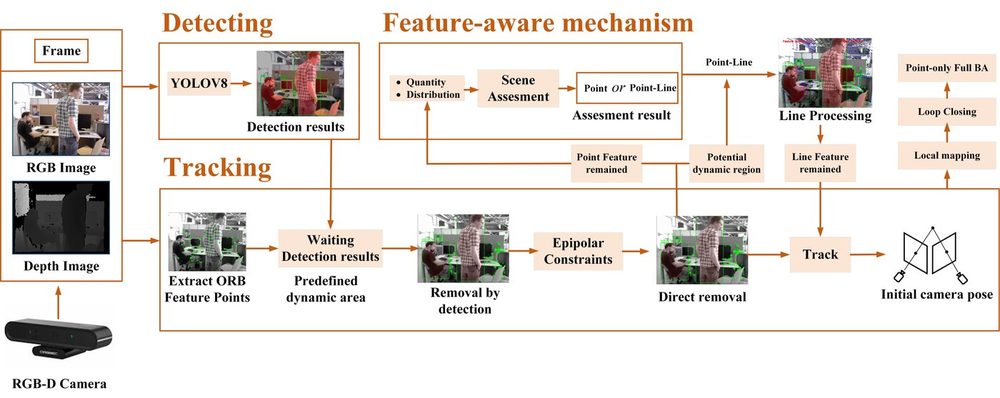
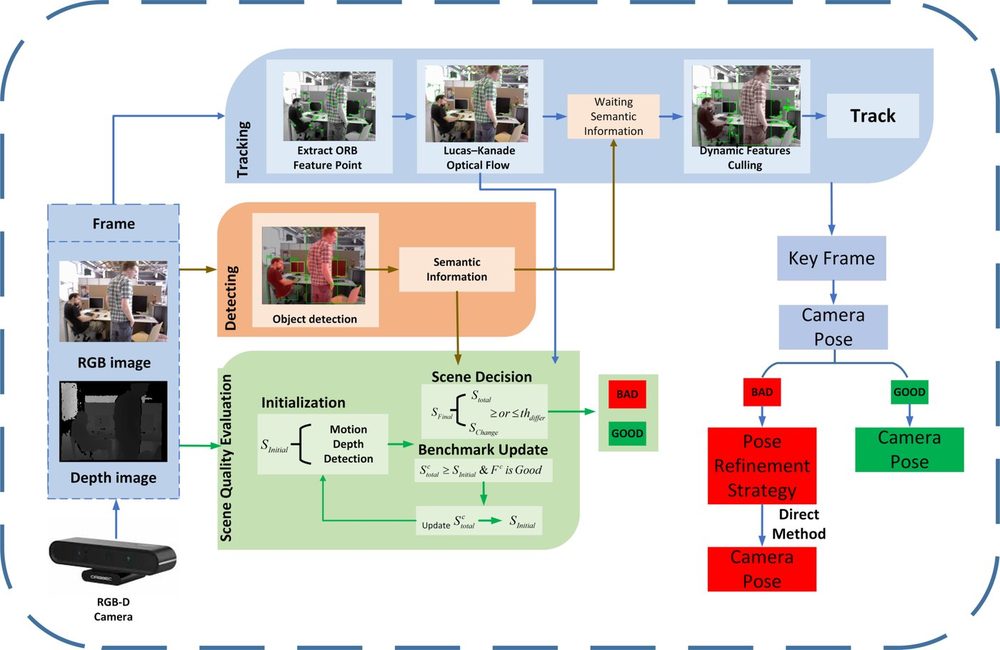
@article{sr-slam,
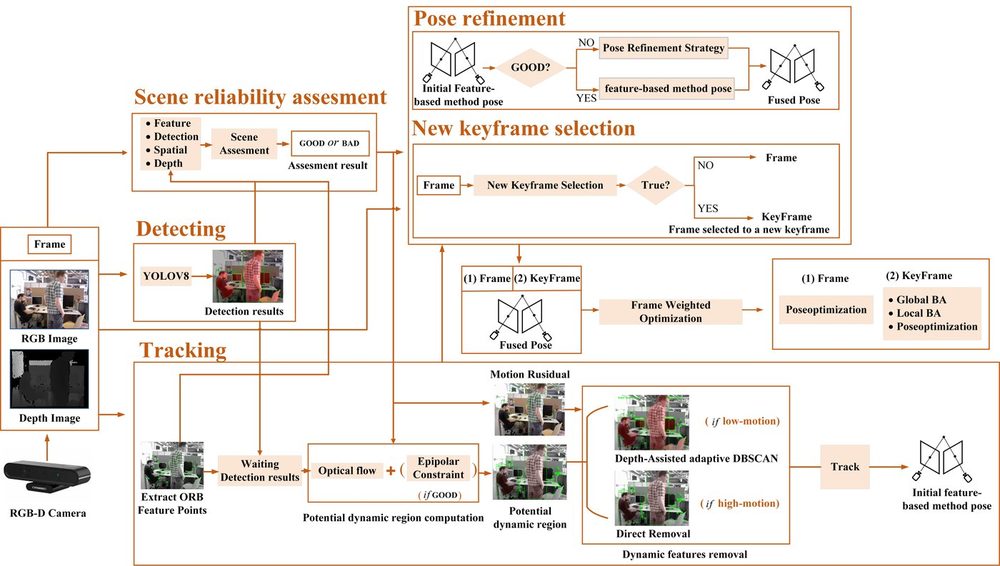
  title = {SR-SLAM: Scene reliability-based RGB-D SLAM in diverse environments},
  author = {Haolan Zhang and Chenghao Li and Thanh Nguyen Canh and Lijun Wang and Nak Young Chong},
  journal = {Robotics and Autonomous Systems},
  year = {2026}
}
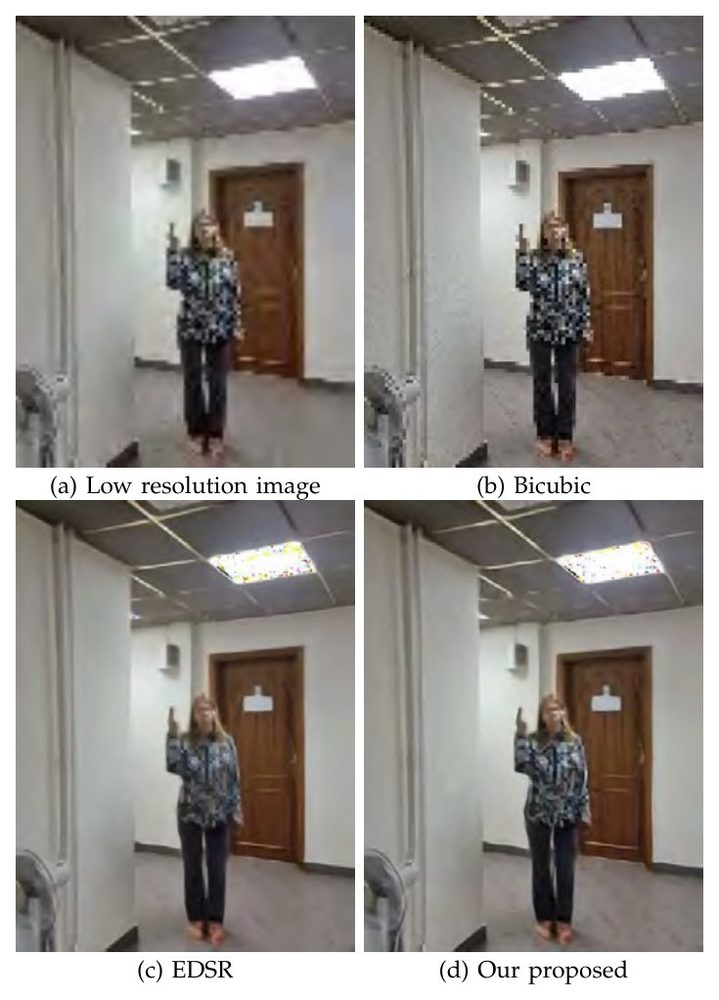
Printed Circuit Boards (PCBs) are critical components in modern electronics, which
require stringent quality control to ensure proper functionality. However, the
detection of defects in small-scale PCBs images poses significant challenges as a
result of the low resolution of the captured images, leading to potential
confusion between defects and noise. To overcome these challenges, this paper
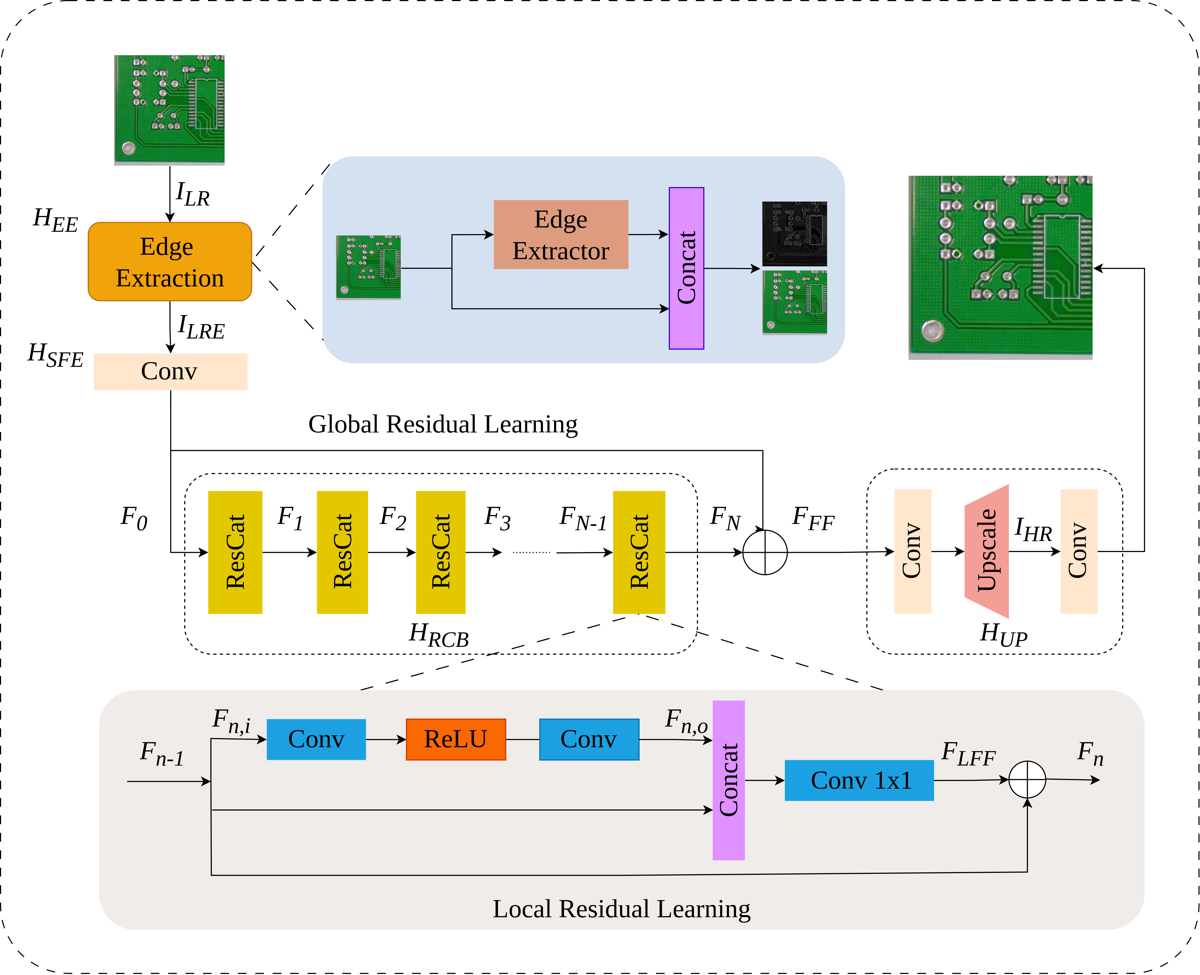
proposes a novel framework, named ESRPCB (edge-guided super-resolution for PCBs
defect detection), which combines edge-guided super-resolution with ensemble
learning to enhance PCBs defect detection. Our approach leverages the edge
information to guide the EDSR (Enhanced Deep Super-Resolution) model with a novel
ResCat (Residual Concatenation) structure, enabling it to reconstruct
high-resolution images from small PCBs inputs. By incorporating edge features, the
super-resolution process preserves critical structural details, ensuring that tiny
defects remain distinguishable in the enhanced image. Following this, a
multi-modal defect detection model employs ensemble learning to analyze the
super-resolved image, improving the accuracy of defect identification.
Experimental results demonstrate that ESRPCB achieves superior performance
compared to State-of-the-Art (SOTA) methods. Our model attains an average Peak
Signal to Noise Ratio (PSNR) of 30.54 dB(decibel), surpassing EDSR by 0.42dB. In
defect detection, ESRPCB achieves a mAP50(mean average precision at an
Intersection over Union threshold of 0.50) of 0.965, surpassing EDSR (0.905) and
traditional super-resolution models by over 5%. Furthermore, our ensemble-based
detection approach further enhances performance, achieving a mAP50 of 0.977. These
results highlight the effectiveness of ESRPCB in enhancing both image quality and
defect detection accuracy, particularly in challenging low-resolution scenarios.
BibTeX
@article{esrpcb,
  title = {ESRPCB: an Edge guided Super-Resolution model and Ensemble learning for tiny Printed Circuit Board Defect detection},
  author = {Xiem HoangVan and Dang Bui Dinh and Thanh Nguyen Canh and Van-Truong Nguyen},
  journal = {Engineering Applications of Artificial Intelligence},
  year = {2025}
}
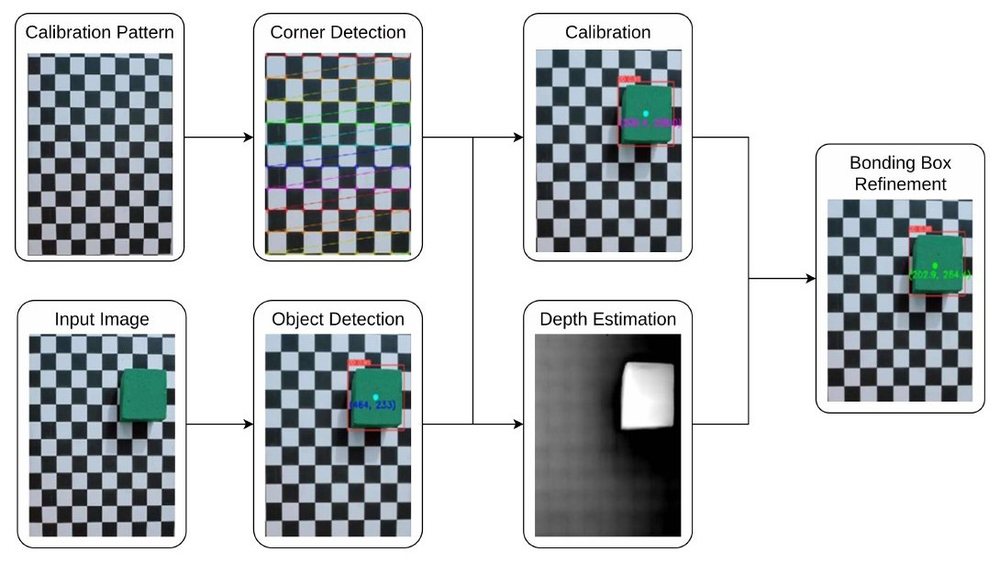
3D Object Localization has been emerging recently as one of the challenges of
Machine Vision or Robot Vision tasks. In this paper, we proposed a novel method
designed for the localization of isometric flat 3D objects, leveraging a blend of
deep learning techniques primarily rooted in object detection, postimage
processing algorithms, and pose estimation. Our approach involves the strategic
application of 3D calibration methods tailored for low-cost industrial robotics
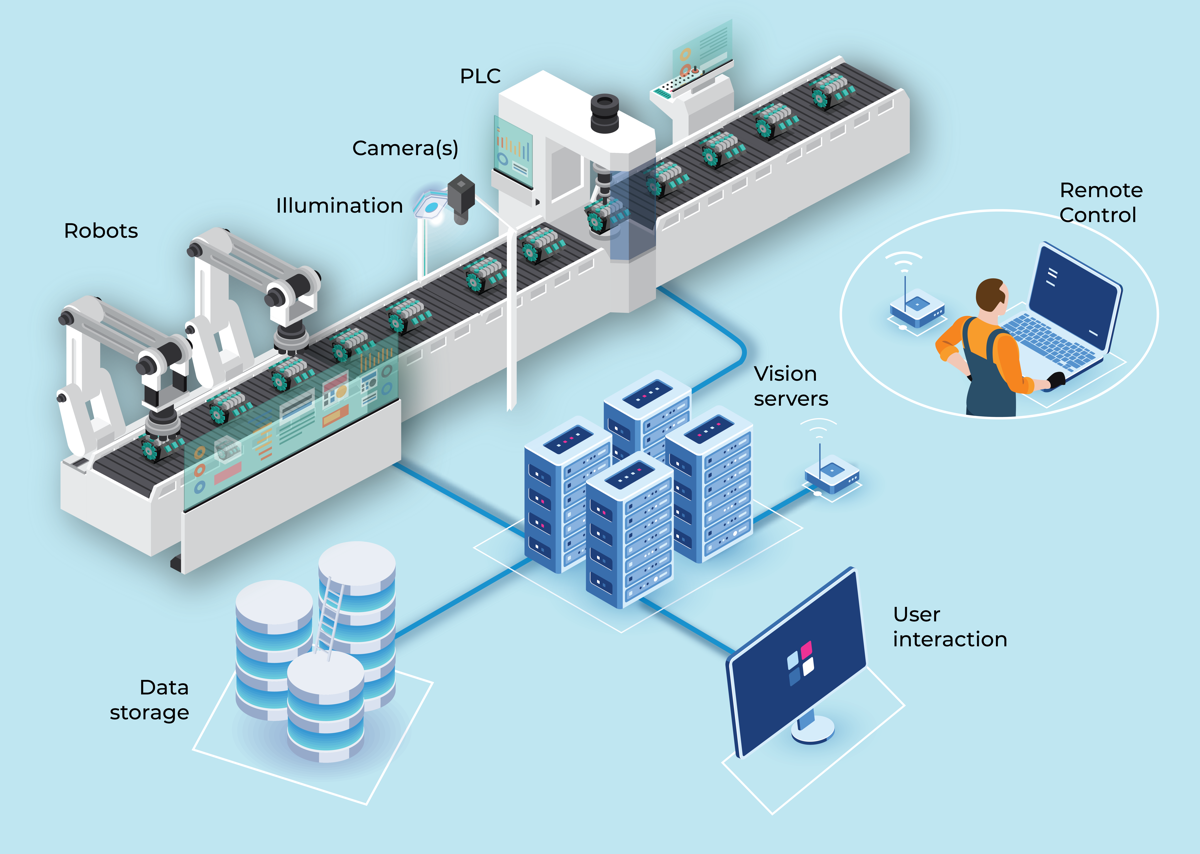
systems, requiring only a single 2D image input. Initially, object detection is
performed using the You Only Look Once (YOLO) model, followed by segmentation of
the object into two distinct parts— the top face and the remainder— using the Mask
R-CNN model. Subsequently, the center of the top face serves as the initialization
position and a unique combination of postprocessing techniques and a novel
calibration algorithm is employed to refine the object’s position. Experimental
results demonstrate a notable reduction in localization error by 87.65% when
compared to existing methodologies.
BibTeX
@article{m-calib,
  title = {M-Calib: A Monocular 3D Object Localization using 2D Estimates for Industrial Robot Vision System},
  author = {Thanh Nguyen Canh and Du Ngoc Trinh and Xiem HoangVan},
  journal = {Journal of Automation, Mobile Robotics and Intelligent Systems (JAMRIS)},
  year = {2025}
}
Journal2025
E2DSR: Edge-Enhanced Representation for Deep Super-Resolution in Machine Vision
Applications
Xiem HoangVan, Long Luong Hai, Thanh Nguyen Canh
REV Journal on Electronics and Communications · 2025
@article{e2dsr,
  title = {E2DSR: Edge-Enhanced Representation for Deep Super-Resolution in Machine Vision Applications},
  author = {Xiem HoangVan and Long Luong Hai and Thanh Nguyen Canh},
  journal = {REV Journal on Electronics and Communications},
  year = {2025}
}
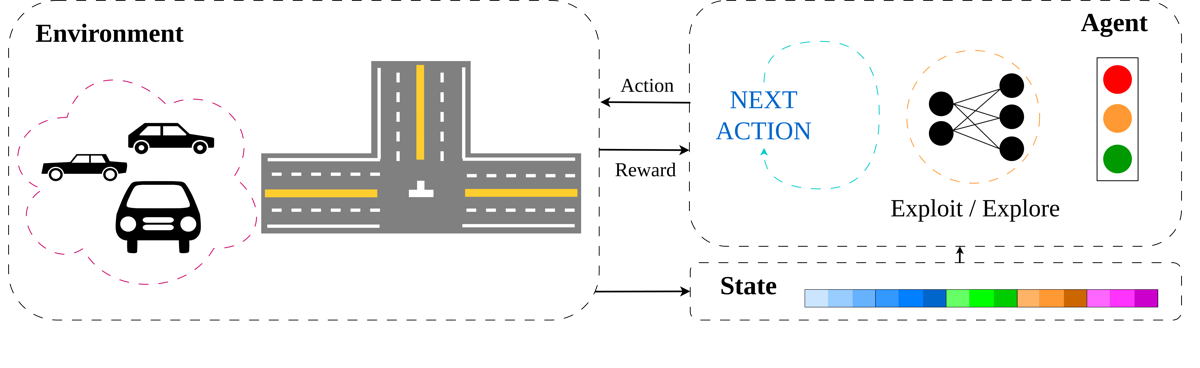
Traffic light control (TSC) is an important and challenging real-world problem
with the aim of reducing travel time as well as saving energy. Recent researches
have numerous attempts to apply intelligent methods for TSC at four-way crossroads
to solve the traffic light scheduling problem. However, there is the limitation of
researches on efficient TSC at three-way crossroads. Therefore, this paper
introduces a novel TSC solution for three-way crossroad environment (TW-TSC). The
proposed TSC method is designed based on a deep reinforcement learning approach,
namely Soft Actor-Critic (TWSAC). Firstly, we create a simulation environment for
three-way crossroads which consists of numerous transportation and two parallel
lanes using Unity framework. Secondly, to achieve practical movements of
transportation in three-way crossroads, we carefully design agents which have a
high impact to the transportation movement, notably the time to wait for traffic
light, the velocity of transportation, and the number of transportation passing
successfully. Finally, to achieve TW-TSC efficiency, we propose a novel reward
function together with a design of TWSAC algorithm. Experimental results show that
the proposed TWSAC in TW-TSC achieves higher performance than both fixed-time TSC
methods and relevant RL algorithms.
BibTeX
@article{three-way-traffic-signal-control,
  title = {Design of Deep Reinforcement Learning Approach for Traffic Signal Control at Three-way Crossroads},
  author = {Thanh Nguyen Canh and Anh Pham Tuan and Xiem HoangVan},
  journal = {Public Transport},
  year = {2024}
}
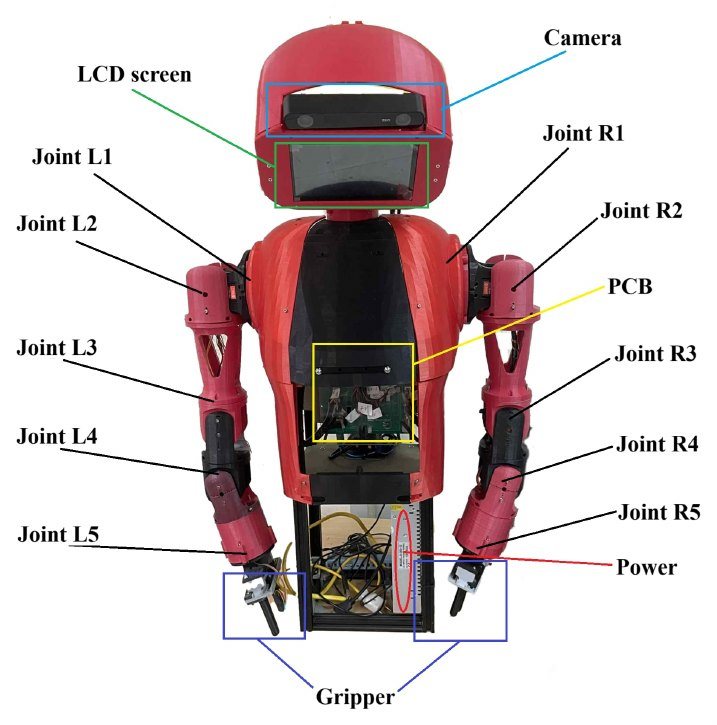
Rapid advancement in robotics technology has paved the way for developing mobile
service robots capable of human interaction and assistance. In this paper, we
propose a comprehensive approach to design, fabricate, and optimize the overall
structure of a dual-arm service robot. The conceptual design phase focuses on both
critical components, the mobile platform and the manipulation system, essential
for seamless navigation and effective task execution. In the proposed system, the
distribution of the robot payload in terms of region, maximum stress, and
displacement is examined, comprehensively analyzed, and compared with the relevant
works. In addition, to enhance the system’s efficiency while minimizing its
weight, we introduce a lightweight design approach in which Finite Element
Analysis is utilized to optimize the frame structure. Subsequently, we fabricate a
physical prototype based on the derived model. Finally, we provide a kinematic
model for our dual-arm service robot and demonstrate its efficacy in both control
and human–robot interaction (HRI) tasks. Experimental results indicate that the
proposed dual arm design can achieve a significant weight reduction of 25% from
the original design while still performing actions smoothly for HRI tasks.
BibTeX
@article{dual-arm-service-robot,
  title = {Optimal design and fabrication of frame structure for dual-arm service robots: An effective approach for human–robot interaction},
  author = {Thanh Nguyen Canh and Son Tran Duc and Huong Nguyen The and Trang Huyen Dao and Xiem HoangVan},
  journal = {Engineering Science and Technology, an International Journal (JESTECH)},
  year = {2024}
}
Conference papers
2026
Conference2026
Decoupled Object-Centric Video Understanding for Generating Robotic Manipulation
Commands
Thanh Nguyen Canh, Tuan Thanh Tran, Haolan Zhang, Z. Gao, Xiem
HoangVan, Nak Young Chong
International Conference on Control, Automation and Systems (ICCAS) · 2026
BibTeX
@inproceedings{decoupled-object-centric-video-understanding,
  title = {Decoupled Object-Centric Video Understanding for Generating Robotic Manipulation Commands},
  author = {Thanh Nguyen Canh and Tuan Thanh Tran and Haolan Zhang and Z. Gao and Xiem HoangVan and Nak Young Chong},
  booktitle = {International Conference on Control, Automation and Systems (ICCAS)},
  year = {2026}
}
Conference2026
OWaveSync: Constrained Wavefront Optimization for Synchronized Co-Speech Gestures in
Humanoid Robots
Thanh Nguyen Canh, Thang Tran Viet, G. H. Uong, P. V. Dinh, T. V.
T. Nguyen, Xiem HoangVan, Nak Young Chong
International Conference on Control, Automation and Systems (ICCAS) · 2026
BibTeX
@inproceedings{owavesync,
  title = {OWaveSync: Constrained Wavefront Optimization for Synchronized Co-Speech Gestures in Humanoid Robots},
  author = {Thanh Nguyen Canh and Thang Tran Viet and G. H. Uong and P. V. Dinh and T. V. T. Nguyen and Xiem HoangVan and Nak Young Chong},
  booktitle = {International Conference on Control, Automation and Systems (ICCAS)},
  year = {2026}
}
Conference2026
OSDAG: Online Scheduling for Efficient Multi-Robot Collaboration
Thanh Nguyen Canh, Thang Tran Viet, P. V. Dinh, Xiem HoangVan, Nak
Young Chong
International Conference on Control, Automation and Systems (ICCAS) · 2026
BibTeX
@inproceedings{osdag,
  title = {OSDAG: Online Scheduling for Efficient Multi-Robot Collaboration},
  author = {Thanh Nguyen Canh and Thang Tran Viet and P. V. Dinh and Xiem HoangVan and Nak Young Chong},
  booktitle = {International Conference on Control, Automation and Systems (ICCAS)},
  year = {2026}
}
Conference2026
Hybrid TD3: Overestimation Bias Analysis and Stable Policy Optimization for Hybrid
Action Space
IEEE International Conference on Automation Science and Engineering (CASE) · 2026
BibTeX
@inproceedings{hybrid-td3,
  title = {Hybrid TD3: Overestimation Bias Analysis and Stable Policy Optimization for Hybrid Action Space},
  author = {Tuan Thanh Tran and Thanh Nguyen Canh and Nak Young Chong and Xiem HoangVan},
  booktitle = {IEEE International Conference on Automation Science and Engineering (CASE)},
  year = {2026}
}
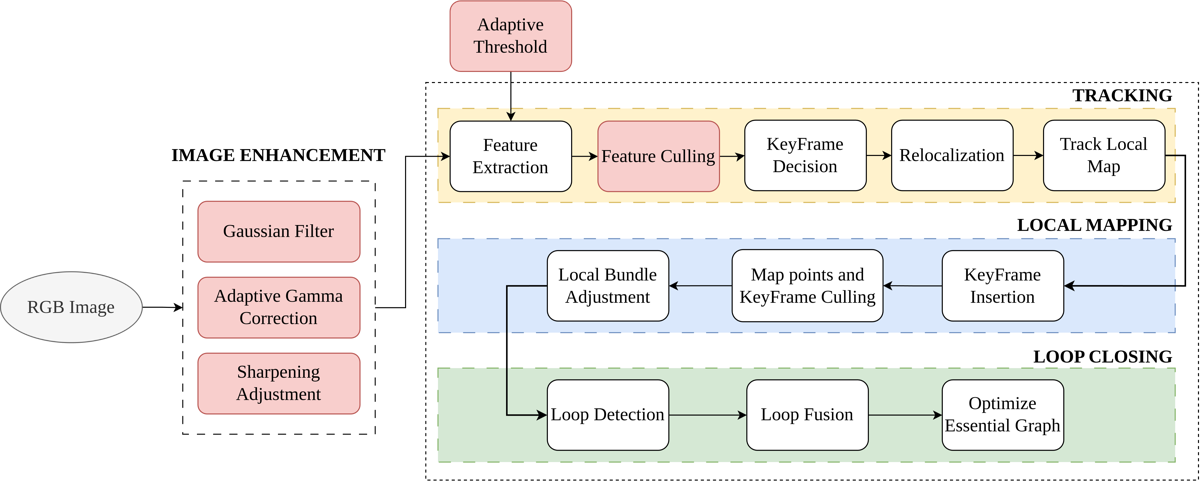
Robust Visual SLAM (vSLAM) is essential for autonomous systems operating in
real-world environments, where challenges such as dynamic objects, low texture,
and critically, varying illumination conditions often degrade performance.
Existing feature-based SLAM systems rely on fixed front-end parameters, making
them vulnerable to sudden lighting changes and unstable feature tracking. To
address these challenges, we propose "IRAF-SLAM", an Illumination-Robust
and Adaptive Feature-Culling front-end designed to enhance vSLAM resilience in
complex and challenging environments. Our approach introduces: (1) an image
enhancement scheme to preprocess and adjust image quality under varying lighting
conditions; (2) an adaptive feature extraction mechanism that dynamically adjusts
detection sensitivity based on image entropy, pixel intensity, and gradient
analysis; and (3) a feature culling strategy that filters out unreliable feature
points using density distribution analysis and a lighting impact factor.
Comprehensive evaluations on the TUM and European Robotics Challenge (EuRoC)
datasets demonstrate that IRAF-SLAM significantly reduces tracking failures and
achieves superior trajectory accuracy compared to state-of-the-art vSLAM methods
under adverse illumination conditions. These results highlight the effectiveness
of adaptive front-end strategies in improving vSLAM robustness without incurring
significant computational overhead.
BibTeX
@inproceedings{iraf-slam,
  title = {IRAF-SLAM: An Illumination-Robust and Adaptive Feature-Culling Front-End for Visual SLAM in Challenging Environments},
  author = {Thanh Nguyen Canh and Bao Nguyen Quoc and HaoLan Zhang and Bupesh Rethinam Veeraiah and Xiem HoangVan and Nak Young Chong},
  booktitle = {European Conference on Mobile Robots (ECMR)},
  year = {2025}
}
Conference2025
IL-SLAM: Intelligent Line-assisted SLAM Based on Feature Awareness for Dynamic
Environments
Haolan Zhang, Thanh Nguyen Canh, Chenghao Li, Ruidong Yang,
Yonghoon Ji, Nak Young Chong
International Conference on Robotic Computing and Communication (RoboticCC) · 2025
@inproceedings{il-slam,
  title = {IL-SLAM: Intelligent Line-assisted SLAM Based on Feature Awareness for Dynamic Environments},
  author = {Haolan Zhang and Thanh Nguyen Canh and Chenghao Li and Ruidong Yang and Yonghoon Ji and Nak Young Chong},
  booktitle = {International Conference on Robotic Computing and Communication (RoboticCC)},
  year = {2025}
}
Conference2025
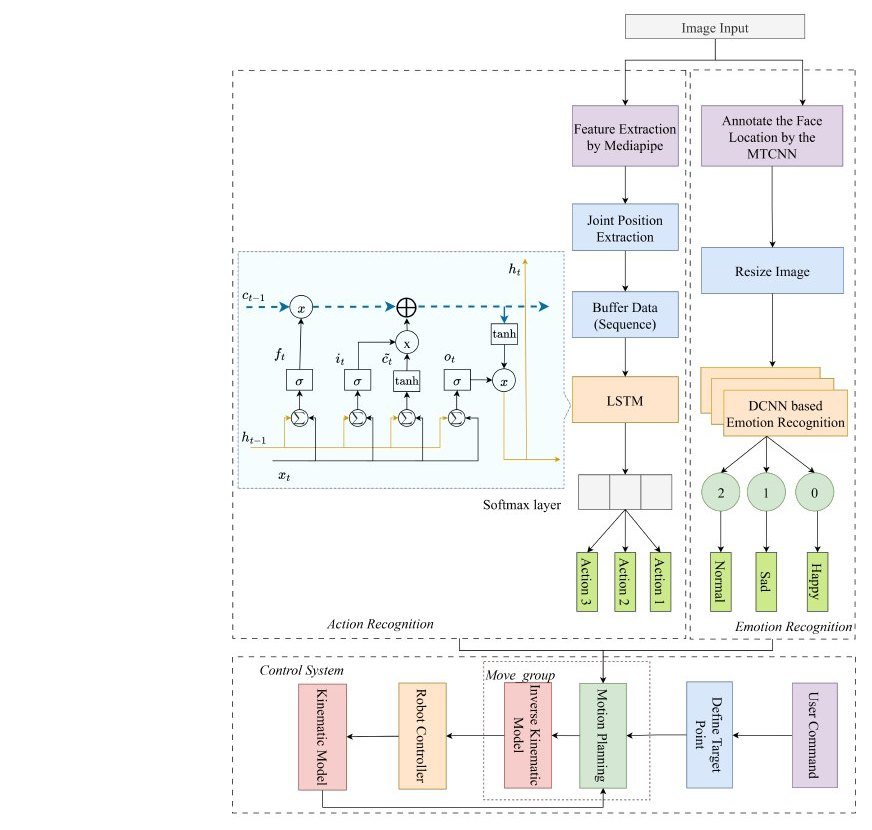
Development of a Humanoid Robot Prototype and Gesture and Voice-Based Interaction
Approach
Thang Tran Viet, Phuc Dinh Van, Huy Uong Gia, Son Tran Duc,
Thanh Nguyen Canh, Xiem HoangVan
International Conference on Advances in Information and Communication Technology
(RIVF) · 2025
BibTeX
@inproceedings{humanoid-gesture-voice-interaction,
  title = {Development of a Humanoid Robot Prototype and Gesture and Voice-Based Interaction Approach},
  author = {Thang Tran Viet and Phuc Dinh Van and Huy Uong Gia and Son Tran Duc and Thanh Nguyen Canh and Xiem HoangVan},
  booktitle = {International Conference on Advances in Information and Communication Technology (RIVF)},
  year = {2025}
}
Conference2025
Refined 3D Object Localization with Monocular Camera using Depth Estimation and
Geometric Refinement
International Conference on Interactive Collaborative Robotics (ICR) · 2025
BibTeX
@inproceedings{refined-monocular-3d-localization,
  title = {Refined 3D Object Localization with Monocular Camera using Depth Estimation and Geometric Refinement},
  author = {Thanh Nguyen Canh and Quang Minh Trinh and Thai-Viet Dang and Phan Xuan Tan and Xiem HoangVan},
  booktitle = {International Conference on Interactive Collaborative Robotics (ICR)},
  year = {2025}
}
Conference2025
Efficient Human-Robot Interaction via Deep Perception and flexible Motion Planning
International Conference on Interactive Collaborative Robotics (ICR) · 2025
BibTeX
@inproceedings{efficient-human-robot-interaction,
  title = {Efficient Human-Robot Interaction via Deep Perception and flexible Motion Planning},
  author = {Thanh Nguyen Canh and Thang Tran Viet and Son Tran Duc and Huong Nguyen The and Trang Huyen Dao and Viet-Ha Nguyen and Xiem HoangVan},
  booktitle = {International Conference on Interactive Collaborative Robotics (ICR)},
  year = {2025}
}
Conference2025
Adaptive Prior Scene-Object SLAM for Dynamic Environments
Haolan Zhang, Thanh Nguyen Canh, Chenghao Li, Nak Young Chong
IEEE International Conference on Real-time Computing and Robotics (RCAR) · 2025 ·
accepted
BibTeX
@inproceedings{adaptive-prior-scene-object-slam,
  title = {Adaptive Prior Scene-Object SLAM for Dynamic Environments},
  author = {Haolan Zhang and Thanh Nguyen Canh and Chenghao Li and Nak Young Chong},
  booktitle = {IEEE International Conference on Real-time Computing and Robotics (RCAR)},
  year = {2025}
}
Conference2025
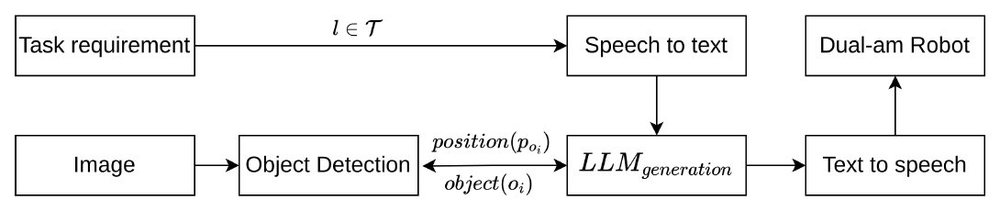
Context-aware LLM-based Human-Robot Interaction
Thanh Nguyen Canh, Kien HoangVan, Xiem HoangVan
International Conference on Intelligent Systems & Networks (ICISN) · 2025 ·
accepted
BibTeX
@inproceedings{context-aware-llm-human-robot-interaction,
  title = {Context-aware LLM-based Human-Robot Interaction},
  author = {Thanh Nguyen Canh and Kien HoangVan and Xiem HoangVan},
  booktitle = {International Conference on Intelligent Systems & Networks (ICISN)},
  year = {2025}
}
This paper presents a novel approach to address challenges in semantic information
extraction and utilization within UAV operations. Our system integrates
state-of-the-art visual SLAM to estimate a comprehensive 6-DoF pose and advanced
object segmentation methods at the back end. To improve the computational and
storage efficiency of the framework, we adopt a streamlined voxel-based 3D map
representation - OctoMap to build a working system. Furthermore, the fusion
algorithm is incorporated to obtain the semantic information of each frame from
the front-end SLAM task, and the corresponding point. By leveraging semantic
information, our framework enhances the UAV's ability to perceive and
navigate through indoor spaces, addressing challenges in pose estimation accuracy
and uncertainty reduction. Through Gazebo simulations, we validate the efficacy of
our proposed system and successfully embed our approach into a Jetson Xavier AGX
unit for real-world applications.
BibTeX
@inproceedings{s3m,
  title = {S3M: Semantic Segmentation Sparse Mapping for UAVs with RGB-D Camera},
  author = {Thanh Nguyen Canh and Van-Truong Nguyen and Xiem HoangVan and Armagan Elibol and Nak Young Chong},
  booktitle = {IEEE/SICE International Symposium on System Integration (SII)},
  year = {2024}
}
Localization is one of the most crucial tasks for Unmanned Aerial Vehicle systems
(UAVs) directly impacting overall performance, which can be achieved with various
sensors and applied to numerous tasks related to search and rescue operations,
object tracking, construction, etc. However, due to the negative effects of
challenging environments, UAVs may lose signals for localization. In this paper,
we present an effective path-planning system leveraging semantic segmentation
information to navigate around texture-less and problematic areas like lakes,
oceans, and high-rise buildings using a monocular camera. We introduce a real-time
semantic segmentation architecture and a novel keyframe decision pipeline to
optimize image inputs based on pixel distribution, reducing processing time. A
hierarchical planner based on the Dynamic Window Approach (DWA) algorithm,
integrated with a cost map, is designed to facilitate efficient path planning. The
system is implemented in a photo-realistic simulation environment using Unity,
aligning with segmentation model parameters. Comprehensive qualitative and
quantitative evaluations validate the effectiveness of our approach, showing
significant improvements in the reliability and efficiency of UAV localization in
challenging environments.
BibTeX
@inproceedings{reliable-uav-localization,
  title = {Toward Integrating Semantic-aware Path Planning and Reliable Localization for UAV Operations},
  author = {Thanh Nguyen Canh and Huy-Hoang Ngo and Xiem HoangVan and Nak Young Chong},
  booktitle = {International Conference on Control, Automation and Systems (ICCAS)},
  year = {2024}
}
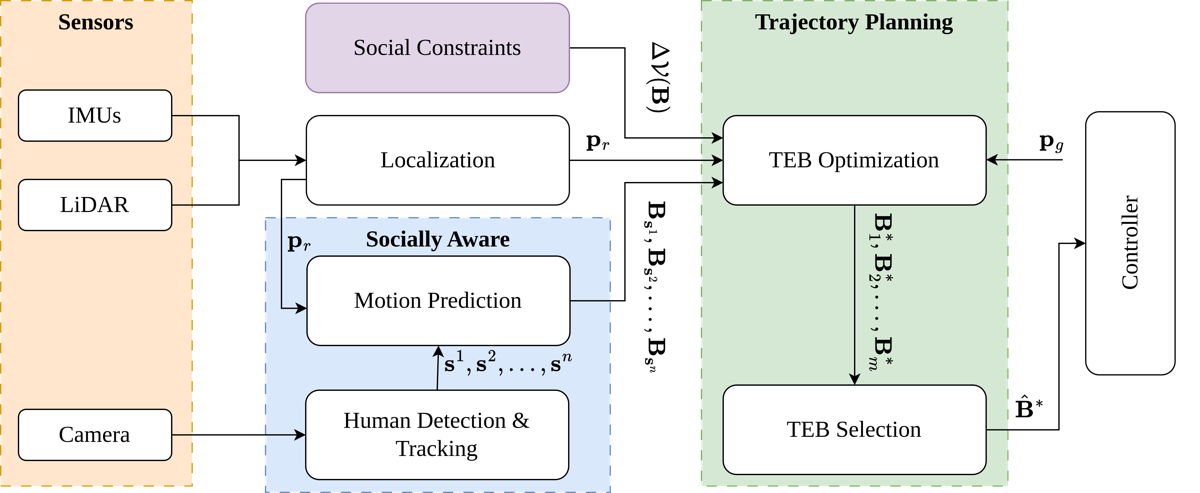
Navigating safely in dynamic human environments is crucial for mobile service
robots, and social navigation is a key aspect of this process. In this paper, we
proposed an integrative approach that combines motion prediction and trajectory
planning to enable safe and socially-aware robot navigation. The main idea of the
proposed method is to leverage the advantages of Socially Acceptable trajectory
prediction and Timed Elastic Band (TEB) by incorporating human interactive
information including position, orientation, and motion into the objective
function of the TEB algorithms. In addition, we designed social constraints to
ensure the safety of robot navigation. The proposed system is evaluated through
physical simulation using both quantitative and qualitative metrics, demonstrating
its superior performance in avoiding human and dynamic obstacles, thereby ensuring
safe navigation.
BibTeX
@inproceedings{social-robot-navigation,
  title = {Enhancing Social Robot Navigation with Integrated Motion Prediction and Trajectory Planning in Dynamic Human Environments},
  author = {Thanh Nguyen Canh and Xiem HoangVan and Nak Young Chong},
  booktitle = {International Conference on Control, Automation and Systems (ICCAS)},
  year = {2024}
}
Conference2024
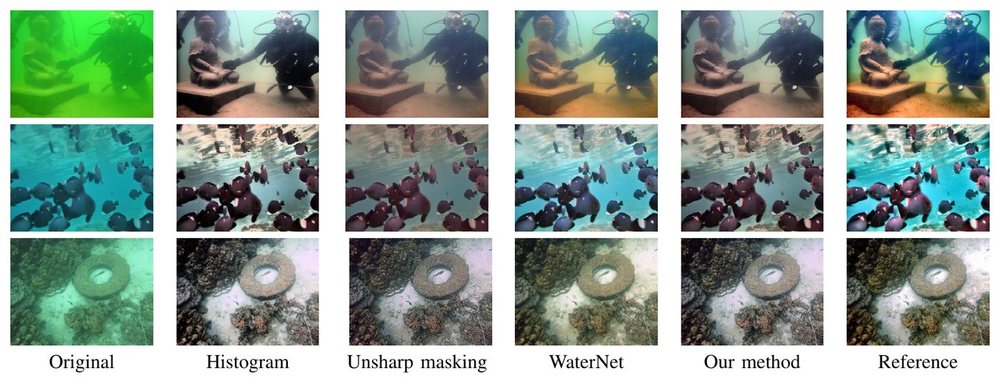
Underwater Image Enhancement for Depth Estimation via Various Image Processing
Techniques
Thanh Nguyen Canh, M. DoNgoc, T. N. Quang, H. B. Thanh, Xiem
HoangVan
International Conference on System Science and Engineering (ICSSE) · 2024
BibTeX
@inproceedings{underwater-image-enhancement,
  title = {Underwater Image Enhancement for Depth Estimation via Various Image Processing Techniques},
  author = {Thanh Nguyen Canh and M. DoNgoc and T. N. Quang and H. B. Thanh and Xiem HoangVan},
  booktitle = {International Conference on System Science and Engineering (ICSSE)},
  year = {2024}
}
Conference2024
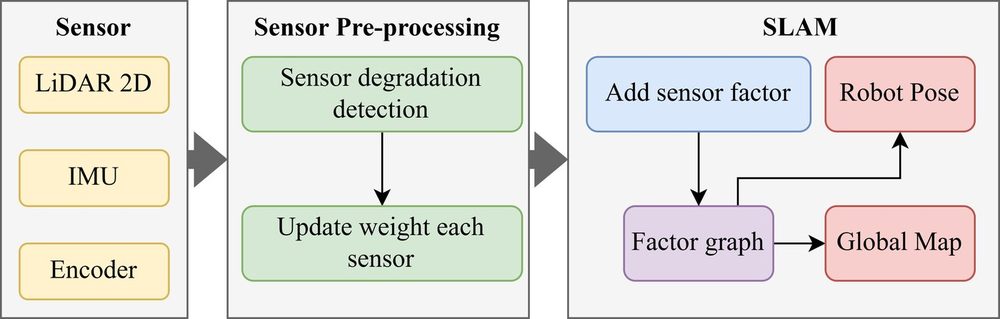
Fusion LiDAR-Inertial-Encoder data for High-Accuracy SLAM
Manh Do Duc, Thanh Nguyen Canh, Minh DoNgoc, Xiem HoangVan
International Conference on Mechatronic, Automobile, and Environment Engineering
(ICMAEE) · 2024
@inproceedings{fusion-lidar-inertial-encoder,
  title = {Fusion LiDAR-Inertial-Encoder data for High-Accuracy SLAM},
  author = {Manh Do Duc and Thanh Nguyen Canh and Minh DoNgoc and Xiem HoangVan},
  booktitle = {International Conference on Mechatronic, Automobile, and Environment Engineering (ICMAEE)},
  year = {2024}
}
To autonomously navigate in real-world environments, special in search and rescue
operations, Unmanned Aerial Vehicles (UAVs) necessitate comprehensive maps to
ensure safety. However, the prevalent metric map often lacks semantic information
crucial for holistic scene comprehension. In this paper, we proposed a system to
construct a probabilistic metric map enriched with object information extracted
from the environment from RGB-D images. Our approach combines a state-of-the-art
YOLOv8-based object detection framework at the front end and a 2D SLAM method -
CartoGrapher at the back end. To effectively track and position semantic object
classes extracted from the front-end interface, we employ the innovative BoT-SORT
methodology. A novel association method is introduced to extract the position of
objects and then project it with the metric map. Unlike previous research, our
approach takes into reliable navigating in the environment with various hollow
bottom objects. The output of our system is a probabilistic map, which
significantly enhances the map's representation by incorporating
object-specific attributes, encompassing class distinctions, accurate positioning,
and object heights. A number of experiments have been conducted to evaluate our
proposed approach. The results show that the robot can effectively produce
augmented semantic maps containing several objects (notably chairs and desks).
Furthermore, our system is evaluated within an embedded computer - Jetson Xavier
AGX unit to demonstrate the use case in real-world applications.
BibTeX
@inproceedings{object-oriented-semantic-mapping,
  title = {Object-Oriented Semantic Mapping for Reliable UAVs Navigation},
  author = {Thanh Nguyen Canh and Armagan Elibol and Nak Young Chong and Xiem HoangVan},
  booktitle = {IEEE International Conference on Control, Automation and Information Sciences (ICCAIS)},
  year = {2023}
}
Conference2023
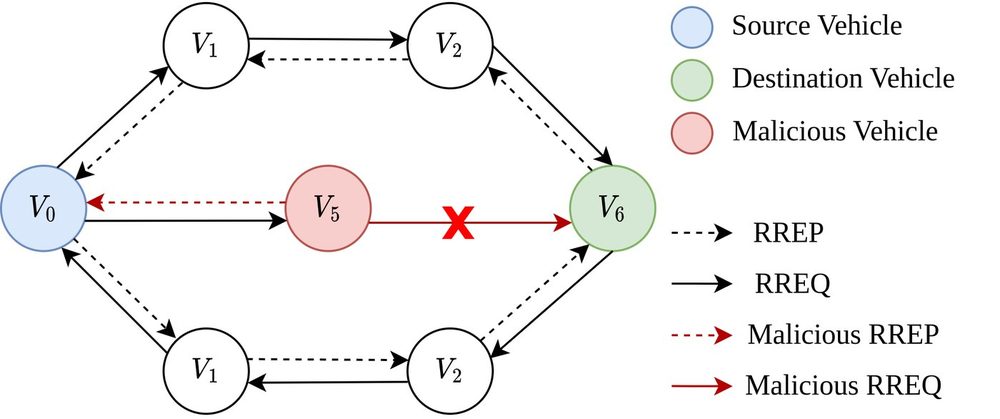
Machine Learning-Based Malicious Vehicle Detection for Security Threats and Attacks
in Vehicle Ad-hoc Network (VANET) Communications
Thanh Nguyen Canh, Xiem HoangVan
IEEE International Conference on Research, Innovation and Vision for the Future
(RIVF) · 2023
@inproceedings{malicious-vehicle-detection,
  title = {Machine Learning-Based Malicious Vehicle Detection for Security Threats and Attacks in Vehicle Ad-hoc Network (VANET) Communications},
  author = {Thanh Nguyen Canh and Xiem HoangVan},
  booktitle = {IEEE International Conference on Research, Innovation and Vision for the Future (RIVF)},
  year = {2023}
}
In this work, we propose a new approach that combines data from multiple sensors
for reliable obstacle avoidance. The sensors include two depth cameras and a LiDAR
arranged so that they can capture the whole 3D area in front of the robot and a 2D
slide around it. To fuse the data from these sensors, we first use an external
camera as a reference to combine data from two depth cameras. A projection
technique is then introduced to convert the 3D point cloud data of the cameras to
its 2D correspondence. An obstacle avoidance algorithm is then developed based on
the dynamic window approach. A number of experiments have been conducted to
evaluate our proposed approach. The results show that the robot can effectively
avoid static and dynamic obstacles of different shapes and sizes in different
environments.
BibTeX
@inproceedings{multisensor-data-fusion,
  title = {Multisensor Data Fusion for Reliable Obstacle Avoidance},
  author = {Thanh Nguyen Canh and Truong Son Nguyen and Cong Hoang Quach and Xiem HoangVan and Manh Duong Phung},
  booktitle = {IEEE International Conference on Control, Automation and Information Sciences (ICCAIS)},
  year = {2022}
}
Preprints & submitted work
2027
Preprint2027
Uncertainty-Guided 2:4 Dynamic Sparse Evidential Learning for Rare-Event Screening
K. H. Nguyen, Thanh Nguyen Canh, Xiem HoangVan
Association for the Advancement of Artificial Intelligence (AAAI) · 2027 · preprint
BibTeX
@unpublished{sparse-evidential-rare-event-screening,
  title = {Uncertainty-Guided 2:4 Dynamic Sparse Evidential Learning for Rare-Event Screening},
  author = {K. H. Nguyen and Thanh Nguyen Canh and Xiem HoangVan},
  note = {Association for the Advancement of Artificial Intelligence (AAAI)},
  year = {2027}
}
Preprint2027
Multi-head Evidential Deep Learning with Adaptive Prior Weight Fusion
K. H. Nguyen, Thanh Nguyen Canh, Xiem HoangVan
Association for the Advancement of Artificial Intelligence (AAAI) · 2027 · preprint
BibTeX
@unpublished{multi-head-evidential-learning,
  title = {Multi-head Evidential Deep Learning with Adaptive Prior Weight Fusion},
  author = {K. H. Nguyen and Thanh Nguyen Canh and Xiem HoangVan},
  note = {Association for the Advancement of Artificial Intelligence (AAAI)},
  year = {2027}
}
Preprint2027
ROCC: Reliability-Gated Obstruction Reasoning with Certified DAG for Clutter
Grasping
IEEE International Conference on Robotics and Automation (ICRA) · 2027 · preprint
BibTeX
@unpublished{rocc,
  title = {ROCC: Reliability-Gated Obstruction Reasoning with Certified DAG for Clutter Grasping},
  author = {Tuan Thanh Tran and Thanh Nguyen Canh and Xiem HoangVan and Nak Young Chong},
  note = {IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2027}
}
2026
Preprint2026
Human-to-Robot Interaction: Learning from Video Demonstration for Robot Imitation
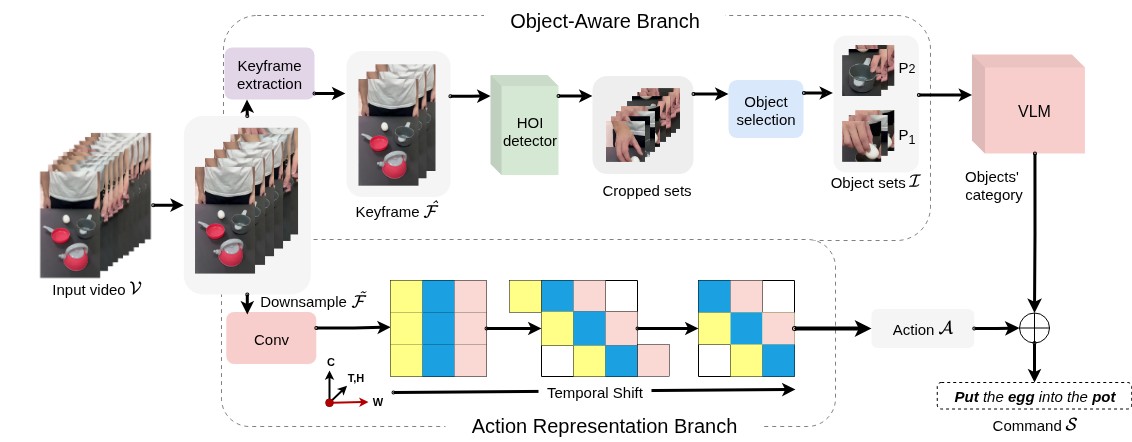
Robotic manipulation through learning from demonstration aims to enable robots to
acquire various actions efficiently. Unlike traditional learning from
observation-action pairs, which is time-consuming and requires proficiency in
coding. Our approach is inspired by the way humans learn and imitate actions in a
more flexible and efficient manner by simply "watching" and
"repeating" the actions. Inspired by this, we propose a
"Human-to-Robot" imitation learning pipeline, which enables robots to
learn diverse actions from video demonstrations. Specifically, we explicitly
represent each step as two key tasks: (1) understanding the demonstration video
and (2) learning the demonstrated manipulations. First, the video description is
achieved by focusing on two essential commonsense properties: action understanding
and object understanding. We utilize deep Convolutional Neural Networks (CNNs) and
Large Vision Models (VLMs) to extract meaningful features related to these
properties. Then, for execution, we develop a robot manipulation system built upon
a Language Vision-conditioned architectures and Deep Reinforcement Learning.
Experiments with real-world video demonstrations. The results show the robustness
and adaptability of the two frameworks in various scenarios using a real robotic
arm UR5.
BibTeX
@unpublished{human-to-robot,
  title = {Human-to-Robot Interaction: Learning from Video Demonstration for Robot Imitation},
  author = {Thanh Nguyen Canh and Tuan Thanh Tran and Xiem HoangVan and Nak Young Chong},
  note = {Autonomous Robots},
  year = {2026}
}
Preprint2026
From Semantic to Affordances: Hierarchical Evidential Semantic-Functional Mapping
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
Preprint · 2026 · preprint
BibTeX
@unpublished{hierarchical-evidential-semantic-functional-mapping,
  title = {From Semantic to Affordances: Hierarchical Evidential Semantic-Functional Mapping},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {Preprint},
  year = {2026}
}
Preprint2026
Compliance-Aware Reinforcement Learning for Active Semantic SLAM with a Soft Aerial
Robot
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{compliance-aware-rl-active-semantic-slam,
  title = {Compliance-Aware Reinforcement Learning for Active Semantic SLAM with a Soft Aerial Robot},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Preprint2026
Contact-Aware Active SLAM with a Soft UAV: Exploiting Compliance for Frontier Goal
Selection
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{contact-aware-active-slam,
  title = {Contact-Aware Active SLAM with a Soft UAV: Exploiting Compliance for Frontier Goal Selection},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Preprint2026
Uncertainty-Aware Open-Vocabulary Semantic Gaussian Splatting for Robust Mapping in
Dynamic Scenes
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{open-vocabulary-semantic-gaussian-splatting,
  title = {Uncertainty-Aware Open-Vocabulary Semantic Gaussian Splatting for Robust Mapping in Dynamic Scenes},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Preprint2026
HESFM-OV: Hierarchical Evidential Semantic-Functional Mapping with Open Vocabulary
for Indoor UAV Navigation
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{hesfm-ov,
  title = {HESFM-OV: Hierarchical Evidential Semantic-Functional Mapping with Open Vocabulary for Indoor UAV Navigation},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Preprint2026
SeLiSLAM: Semantic Lifelong Simultaneous Localization and Mapping for UAVs via
Continual Learning, Open-Vocabulary Ephemerality, and Object Re-Identification
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{selislam,
  title = {SeLiSLAM: Semantic Lifelong Simultaneous Localization and Mapping for UAVs via Continual Learning, Open-Vocabulary Ephemerality, and Object Re-Identification},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
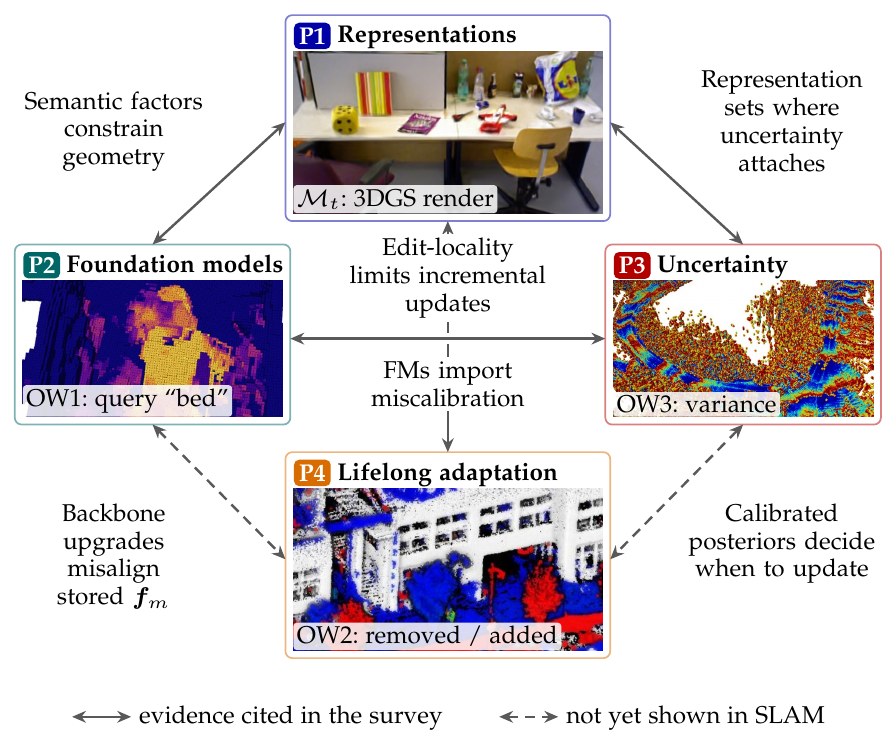
Semantic simultaneous localization and mapping (SLAM) still largely assumes a
closed set of categories, a static world, and deterministic labels. Four
developments each relax one of these assumptions: differentiable scene
representations such as neural radiance fields and 3D Gaussian splatting,
vision–language foundation models, principled uncertainty quantification, and
lifelong mapping. Yet the literature has grown in parallel threads. This survey
argues that these threads are interlocking pillars of a single shift toward
open-world semantic SLAM. Such SLAM operates with open vocabularies, in
non-stationary environments, and with calibrated beliefs over geometry and
meaning. We give a unified probabilistic formulation of the problem and organize
81 systems around four pillars: (P1) map representations, (P2) foundation-model
grounding, (P3) uncertainty, and (P4) lifelong adaptation. We assess the pillars
through 17 explicit claims. A cross-cutting analysis shows how the pillars
constrain one another and that no current system addresses all four. We
consolidate datasets, metrics, and reported results, and argue that closed-world,
single-session benchmarks now limit progress. We close with a reference
architecture and seven open problems for open-world semantic SLAM.
BibTeX
@unpublished{open-world-semantic-slam-survey,
  title = {Open-World Semantic SLAM: A Survey on Representations, Uncertainty, and Lifelong Adaptation},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
Preprint2026
USGLoc: Uncertainty-Aware Semantic Visual Localization from 3D Gaussian Splatting
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{usgloc,
  title = {USGLoc: Uncertainty-Aware Semantic Visual Localization from 3D Gaussian Splatting},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}
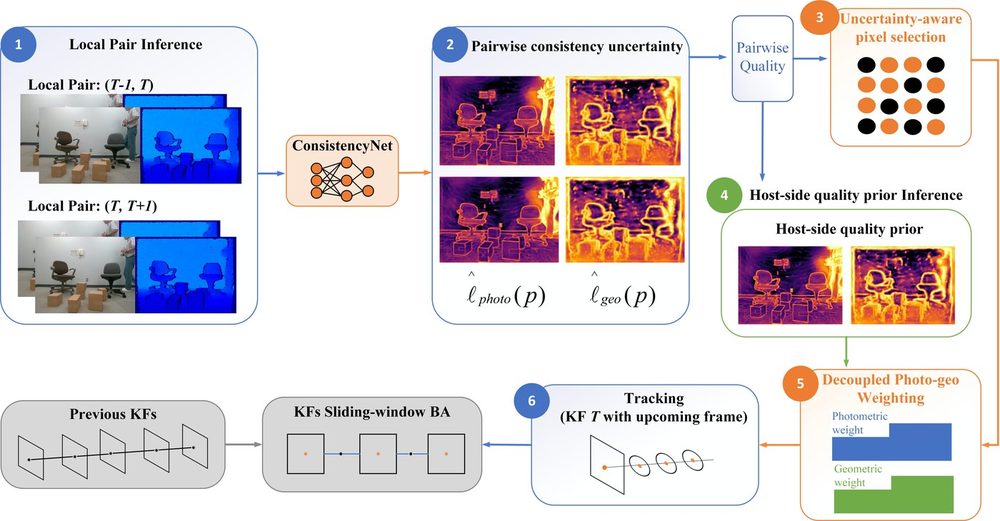
@unpublished{con-dso,
  title = {Con-DSO: Learning Short-Horizon Consistency Priors for RGB-D Direct Sparse Odometry},
  author = {Haolan Zhang and Thanh Nguyen Canh and C. Li and Z. Gao and X. Jiang and Nak Young Chong},
  note = {IEEE Transactions on Multimedia},
  year = {2026}
}
Preprint2026
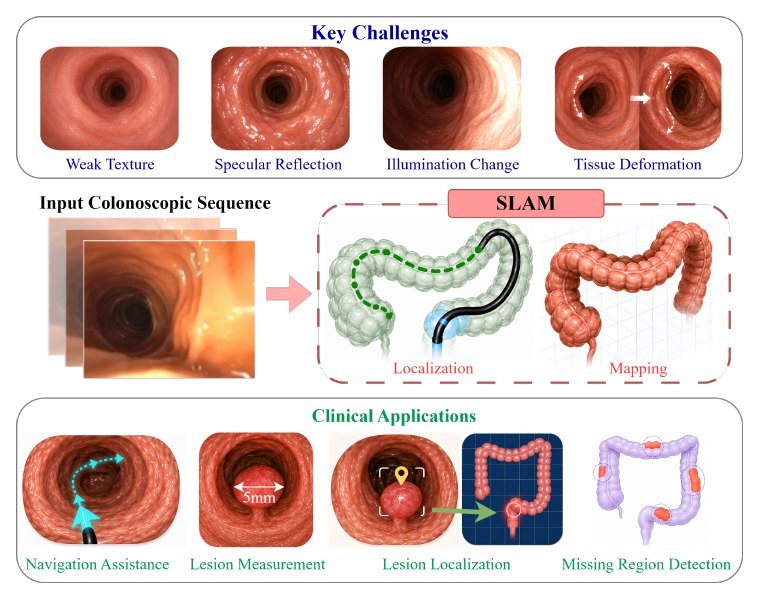
Monocular vSLAM for Colonoscopy: Recent Advances, Benchmarking, and Future
Perspectives
D. M. Do, V. B. Nguyen, Thanh Nguyen Canh, M. T. Thai, Xiem
HoangVan
Robotics and Autonomous Systems · 2026 · preprint
BibTeX
@unpublished{monocular-vslam-colonoscopy-survey,
  title = {Monocular vSLAM for Colonoscopy: Recent Advances, Benchmarking, and Future Perspectives},
  author = {D. M. Do and V. B. Nguyen and Thanh Nguyen Canh and M. T. Thai and Xiem HoangVan},
  note = {Robotics and Autonomous Systems},
  year = {2026}
}
Preprint2026
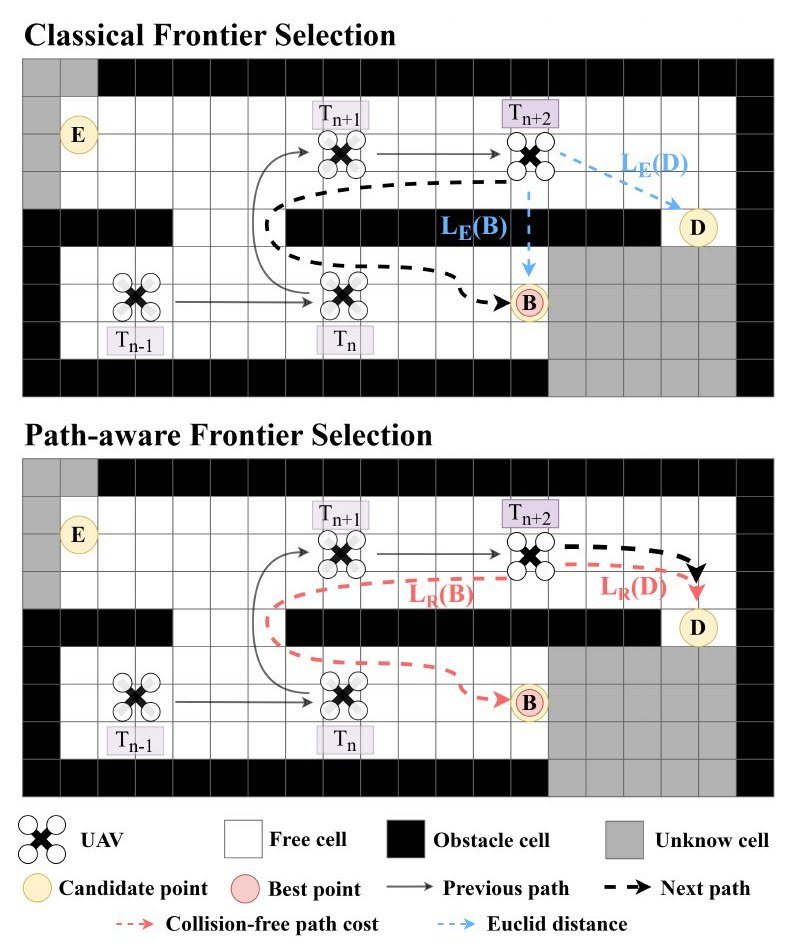
Path-Aware Frontier Selection for UAV-Based Autonomous 3D Exploration
D. M. Do, Thanh Nguyen Canh, N. M. Do, M. T. Thai, Xiem HoangVan
International Conference on Control, Automation, Robotics and Vision (ICARCV) · 2026
· preprint
BibTeX
@unpublished{path-aware-frontier-uav-exploration,
  title = {Path-Aware Frontier Selection for UAV-Based Autonomous 3D Exploration},
  author = {D. M. Do and Thanh Nguyen Canh and N. M. Do and M. T. Thai and Xiem HoangVan},
  note = {International Conference on Control, Automation, Robotics and Vision (ICARCV)},
  year = {2026}
}
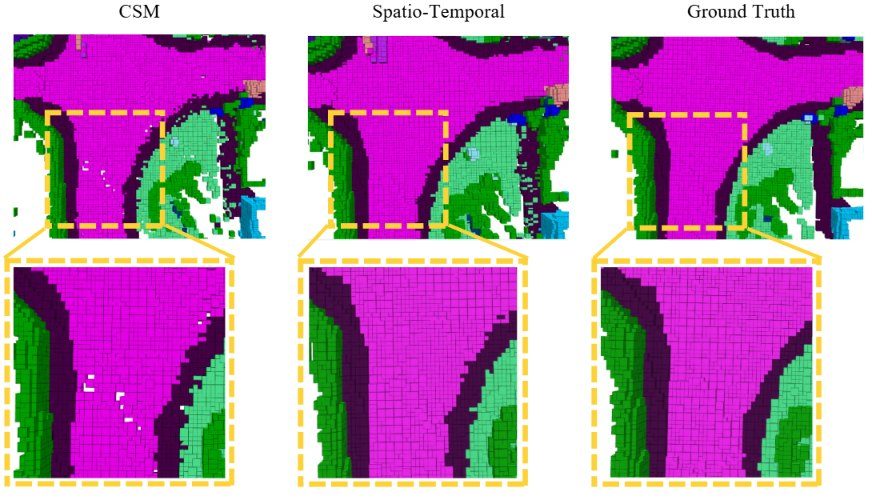
@unpublished{continuous-semantic-mapping,
  title = {Efficient Continuous Semantic Mapping based on Spatio-Temporal Awareness},
  author = {M. L. Pham and D. T. Duong and Xiem HoangVan and Thanh Nguyen Canh},
  note = {International Conference on Control, Automation, Robotics and Vision (ICARCV)},
  year = {2026}
}
Preprint2026
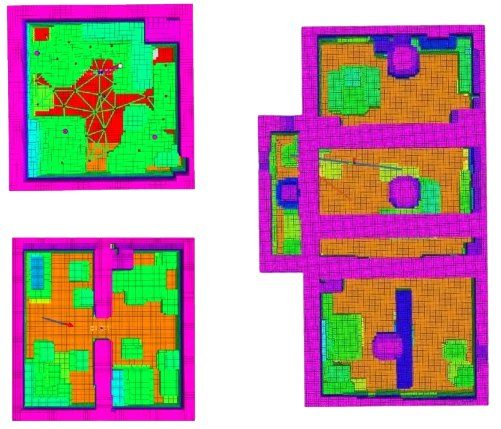
Semantic-Aware Autonomous Exploration for UAVs in Unknown Indoor Environments
D.T. Nguyen, N. M. Do, Xiem HoangVan, Thanh Nguyen Canh
International Conference on Control, Automation, Robotics and Vision (ICARCV) · 2026
· preprint
BibTeX
@unpublished{semantic-aware-uav-exploration,
  title = {Semantic-Aware Autonomous Exploration for UAVs in Unknown Indoor Environments},
  author = {D.T. Nguyen and N. M. Do and Xiem HoangVan and Thanh Nguyen Canh},
  note = {International Conference on Control, Automation, Robotics and Vision (ICARCV)},
  year = {2026}
}
Preprint2026
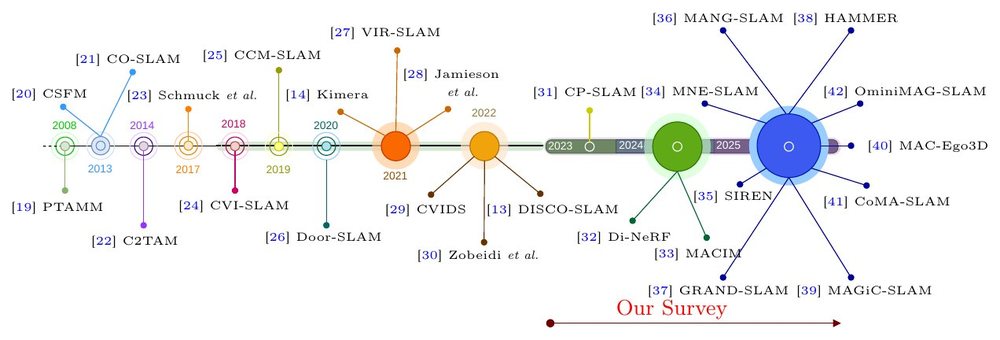
A Survey on Collaborative SLAM with 3D Gaussian Splatting
Thanh Nguyen Canh, P. N. Xuan, H. Nguyen, Nak Young Chong, Xiem
HoangVan
Autonomous Robots · 2026 · under review
BibTeX
@unpublished{collaborative-gaussian-splatting-slam-survey,
  title = {A Survey on Collaborative SLAM with 3D Gaussian Splatting},
  author = {Thanh Nguyen Canh and P. N. Xuan and H. Nguyen and Nak Young Chong and Xiem HoangVan},
  note = {Autonomous Robots},
  year = {2026}
}
Preprint2026
HELIX: Hierarchical Evidential Loop-closure and Information eXploration for Active
Semantic SLAM in GPS-Denied Environments
Thanh Nguyen Canh, Haolan Zhang, Xiem HoangVan, Nak Young Chong
IEEE Robotics and Automation Letters (RA-L) · 2026 · preprint
BibTeX
@unpublished{helix,
  title = {HELIX: Hierarchical Evidential Loop-closure and Information eXploration for Active Semantic SLAM in GPS-Denied Environments},
  author = {Thanh Nguyen Canh and Haolan Zhang and Xiem HoangVan and Nak Young Chong},
  note = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2026}
}