Code · SLAM
BPDA-GMM: Bayesian Probabilistic Data Association via Gaussian Mixture Models for Semantic SLAM
IEEE Robotics and Automation Letters (RA-L) · 2026
Open research resources
Implementations and research resources for semantic mapping, robot learning, navigation and computer vision.
Code · SLAM
IEEE Robotics and Automation Letters (RA-L) · 2026
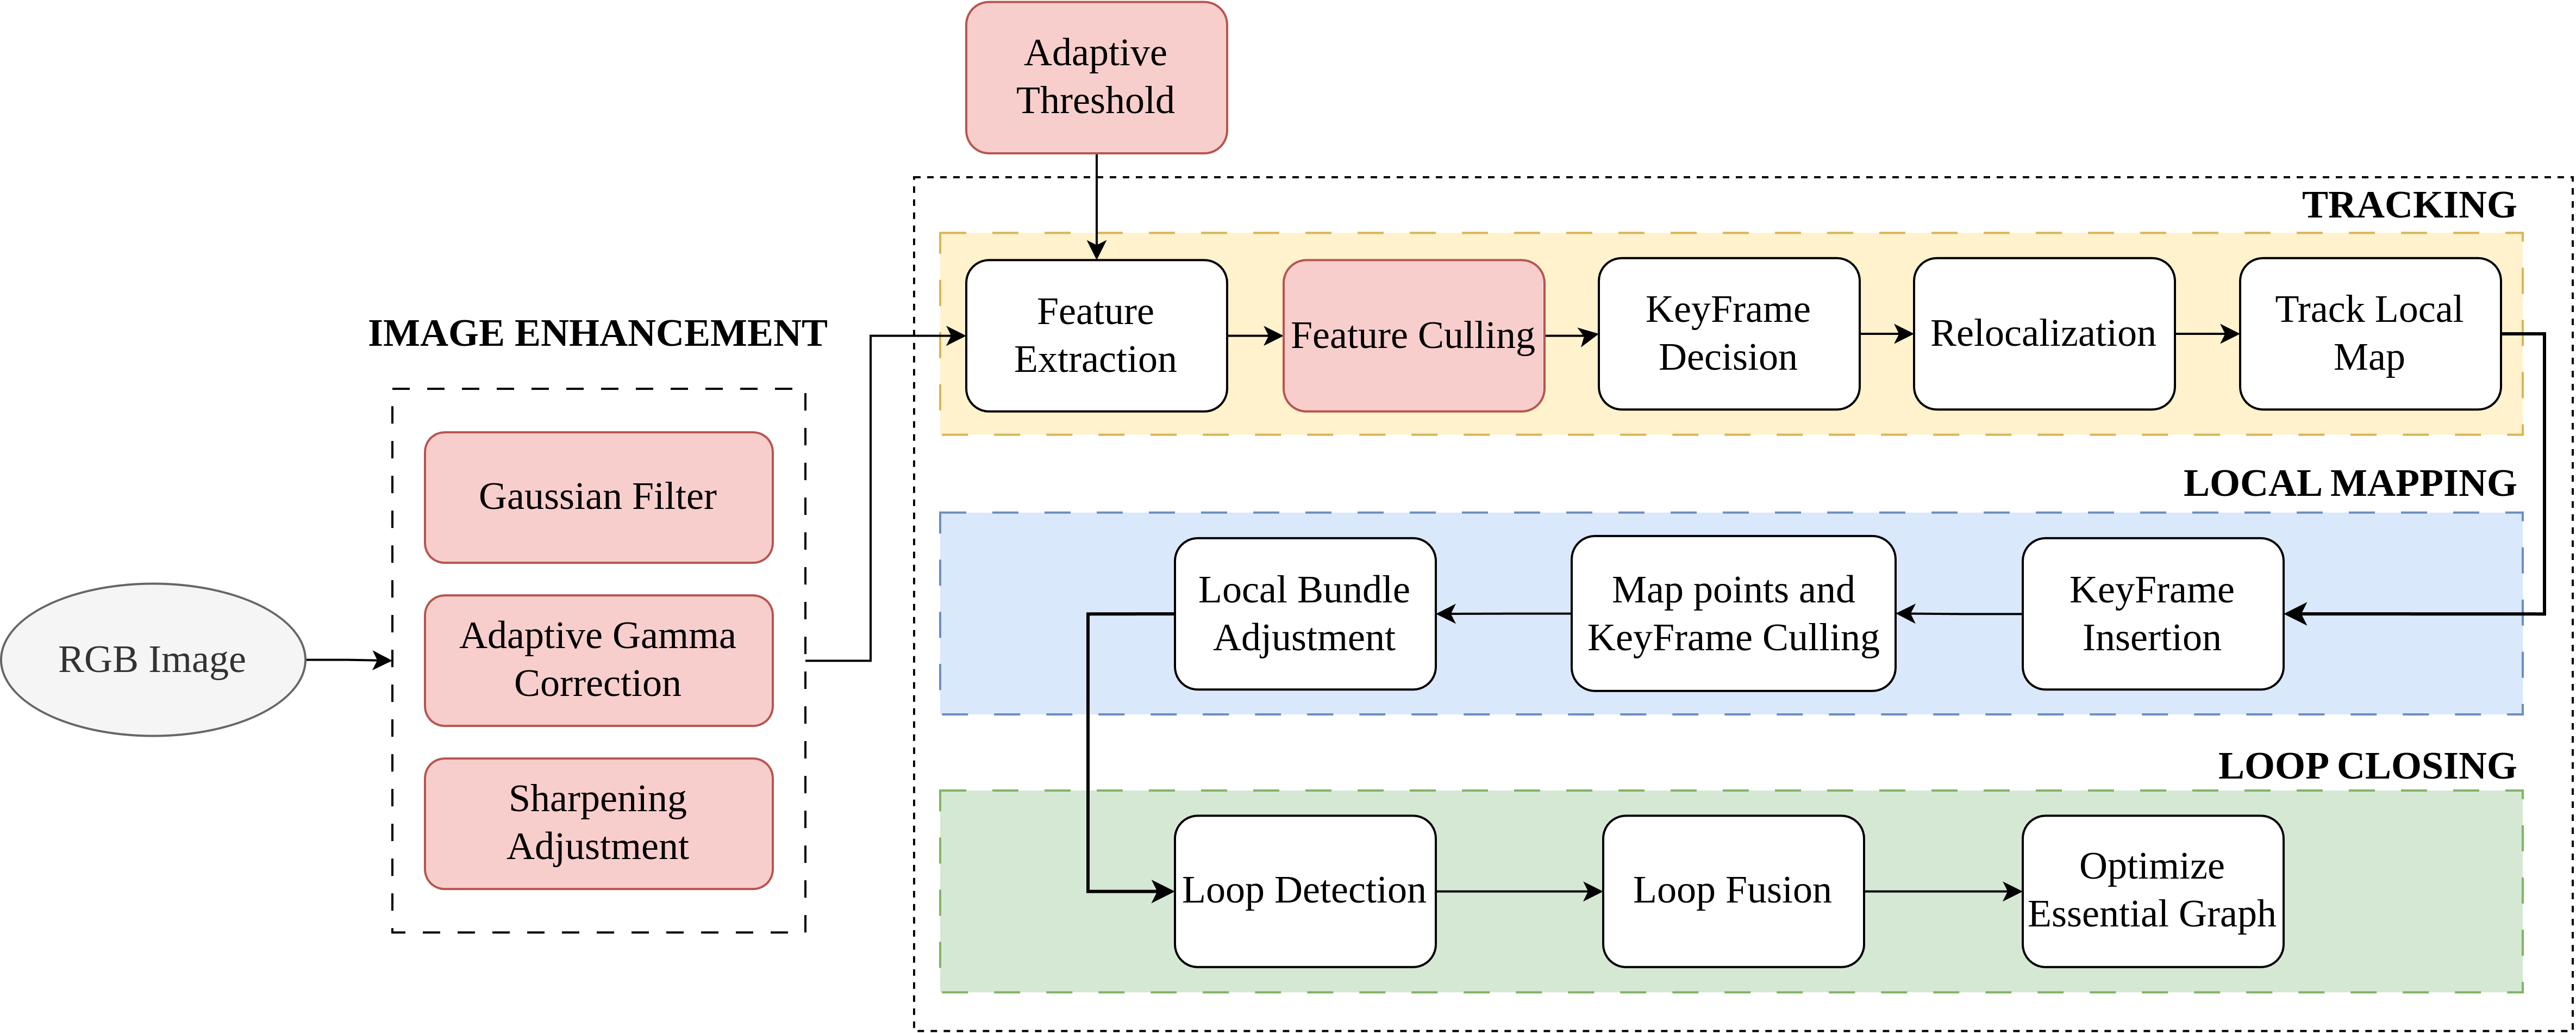
Code · SLAM
European Conference on Mobile Robots (ECMR) · 2025
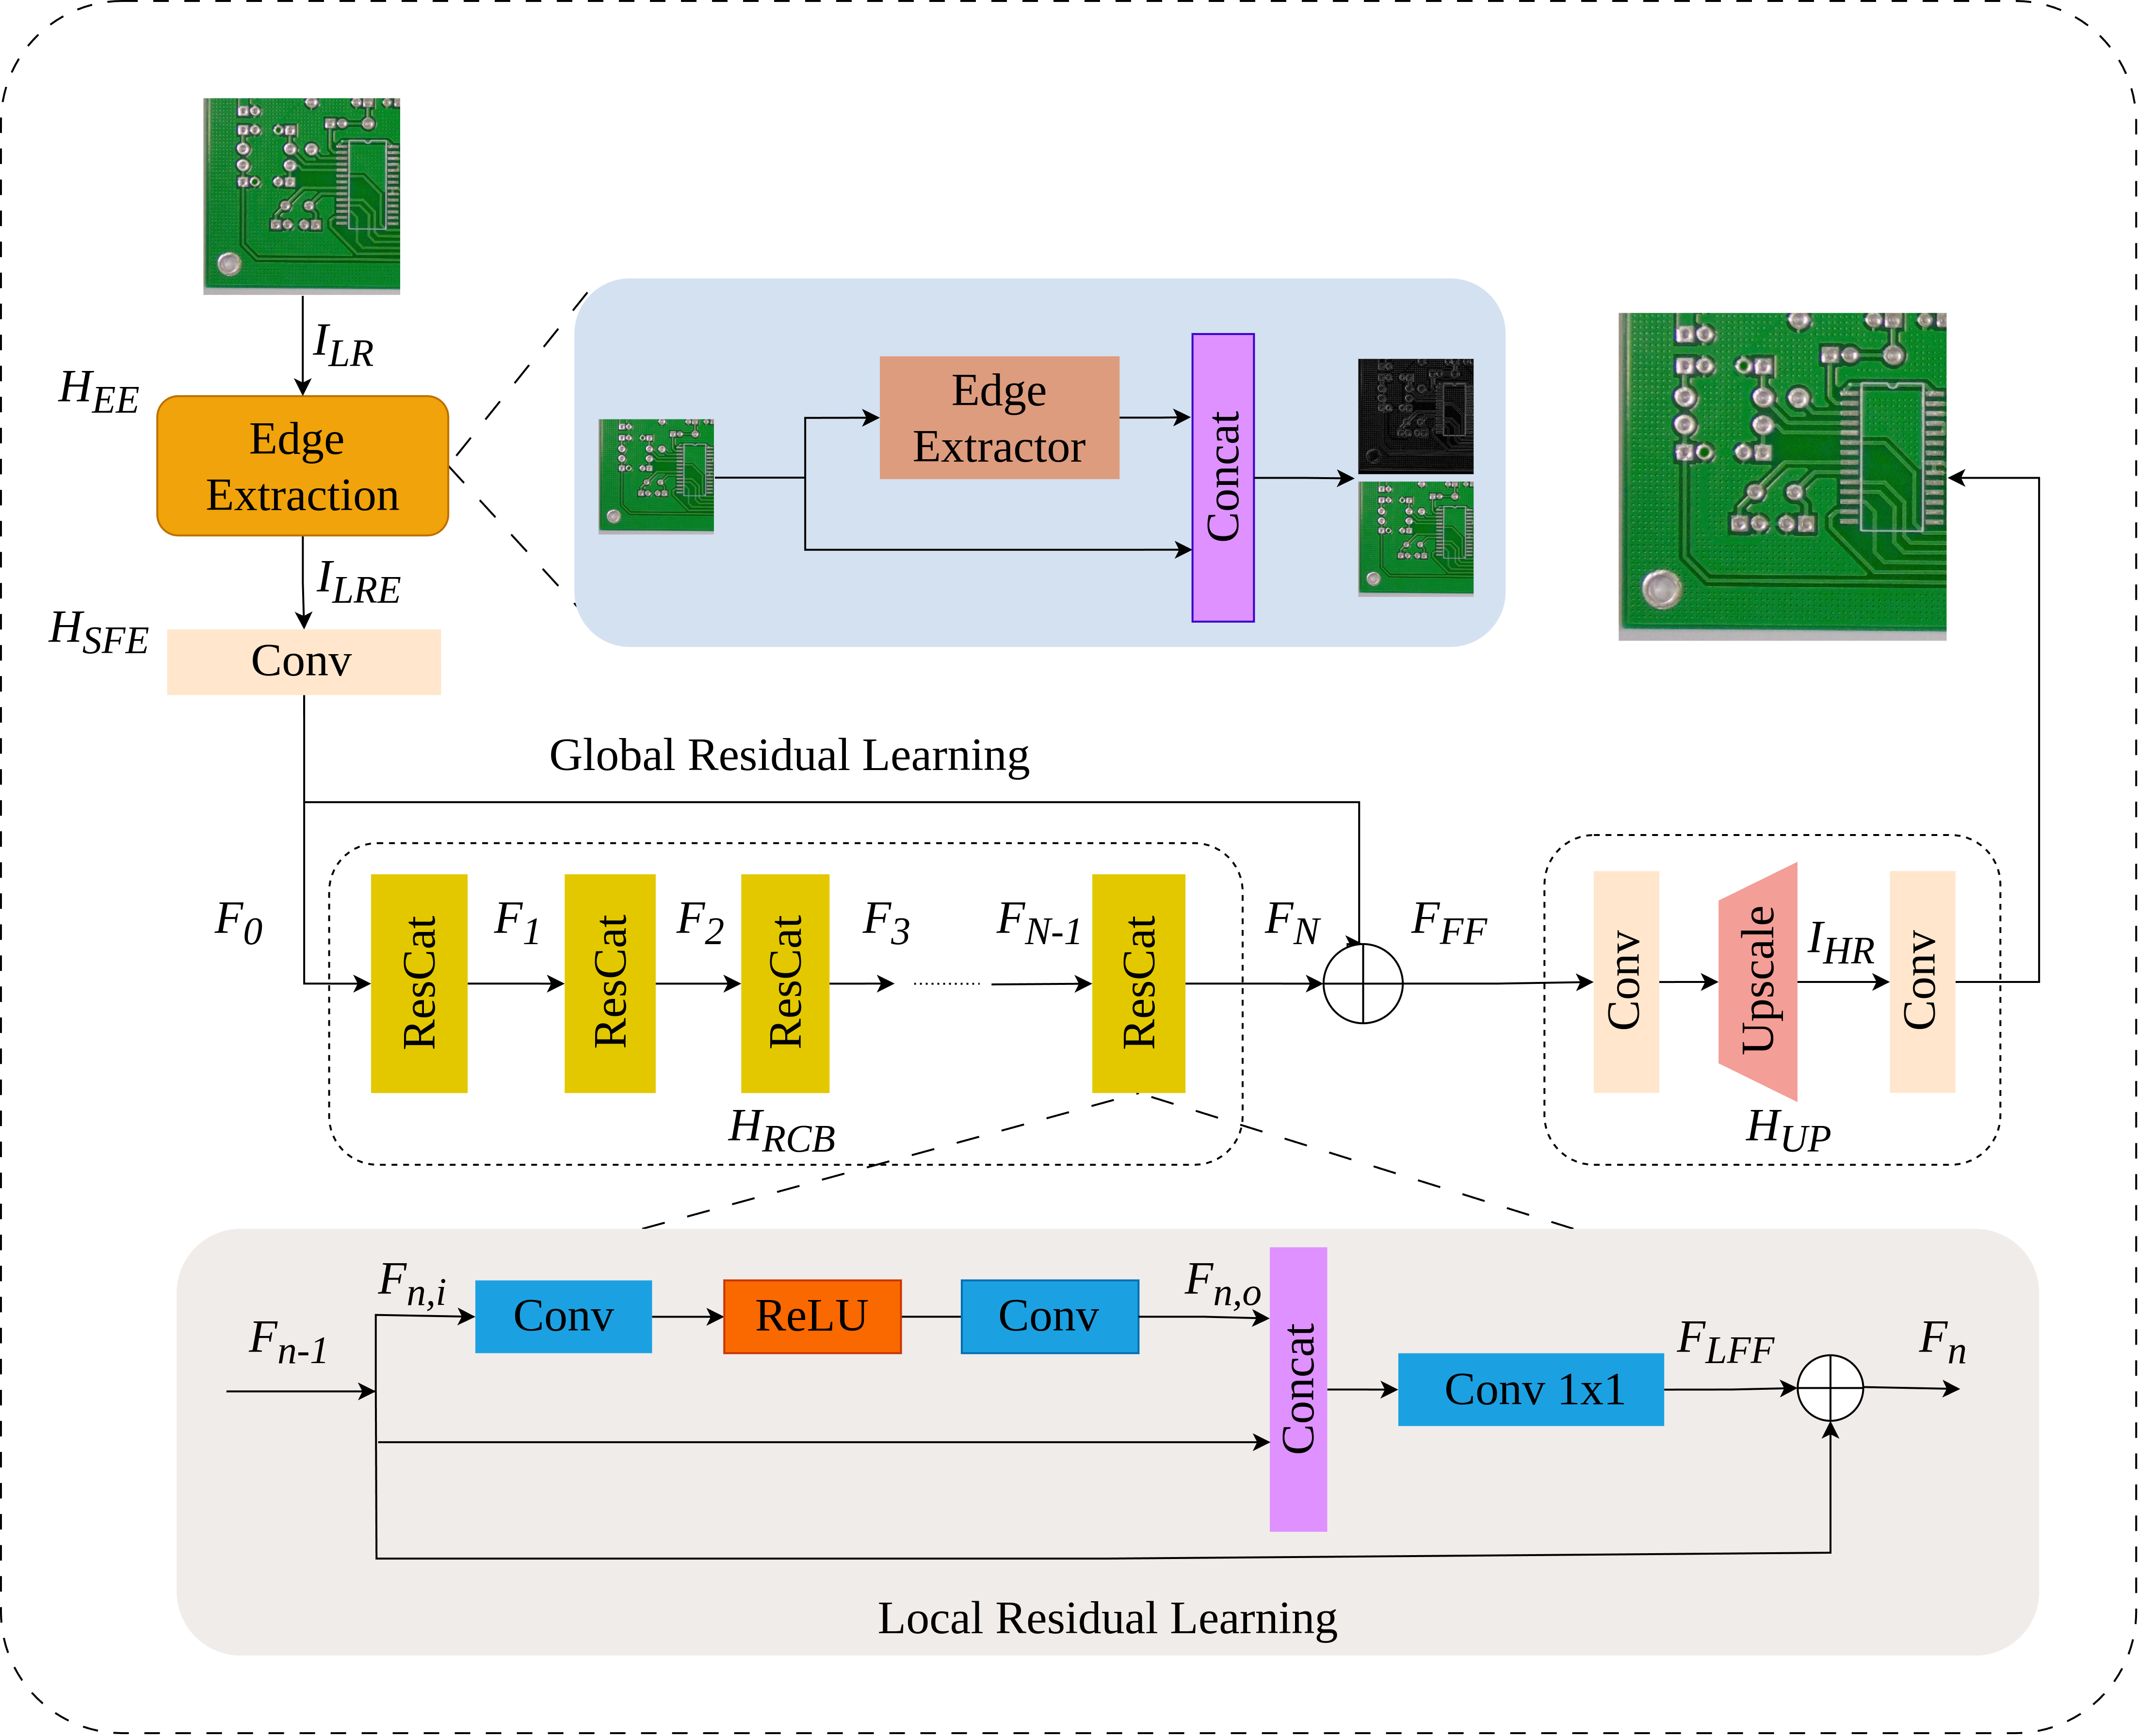
Code · Machine vision
Engineering Applications of Artificial Intelligence · 2025
Code · Machine vision
Journal of Automation, Mobile Robotics and Intelligent Systems (JAMRIS) · 2025
Code · Semantic SLAM
IEEE/SICE International Symposium on System Integration (SII) · 2024
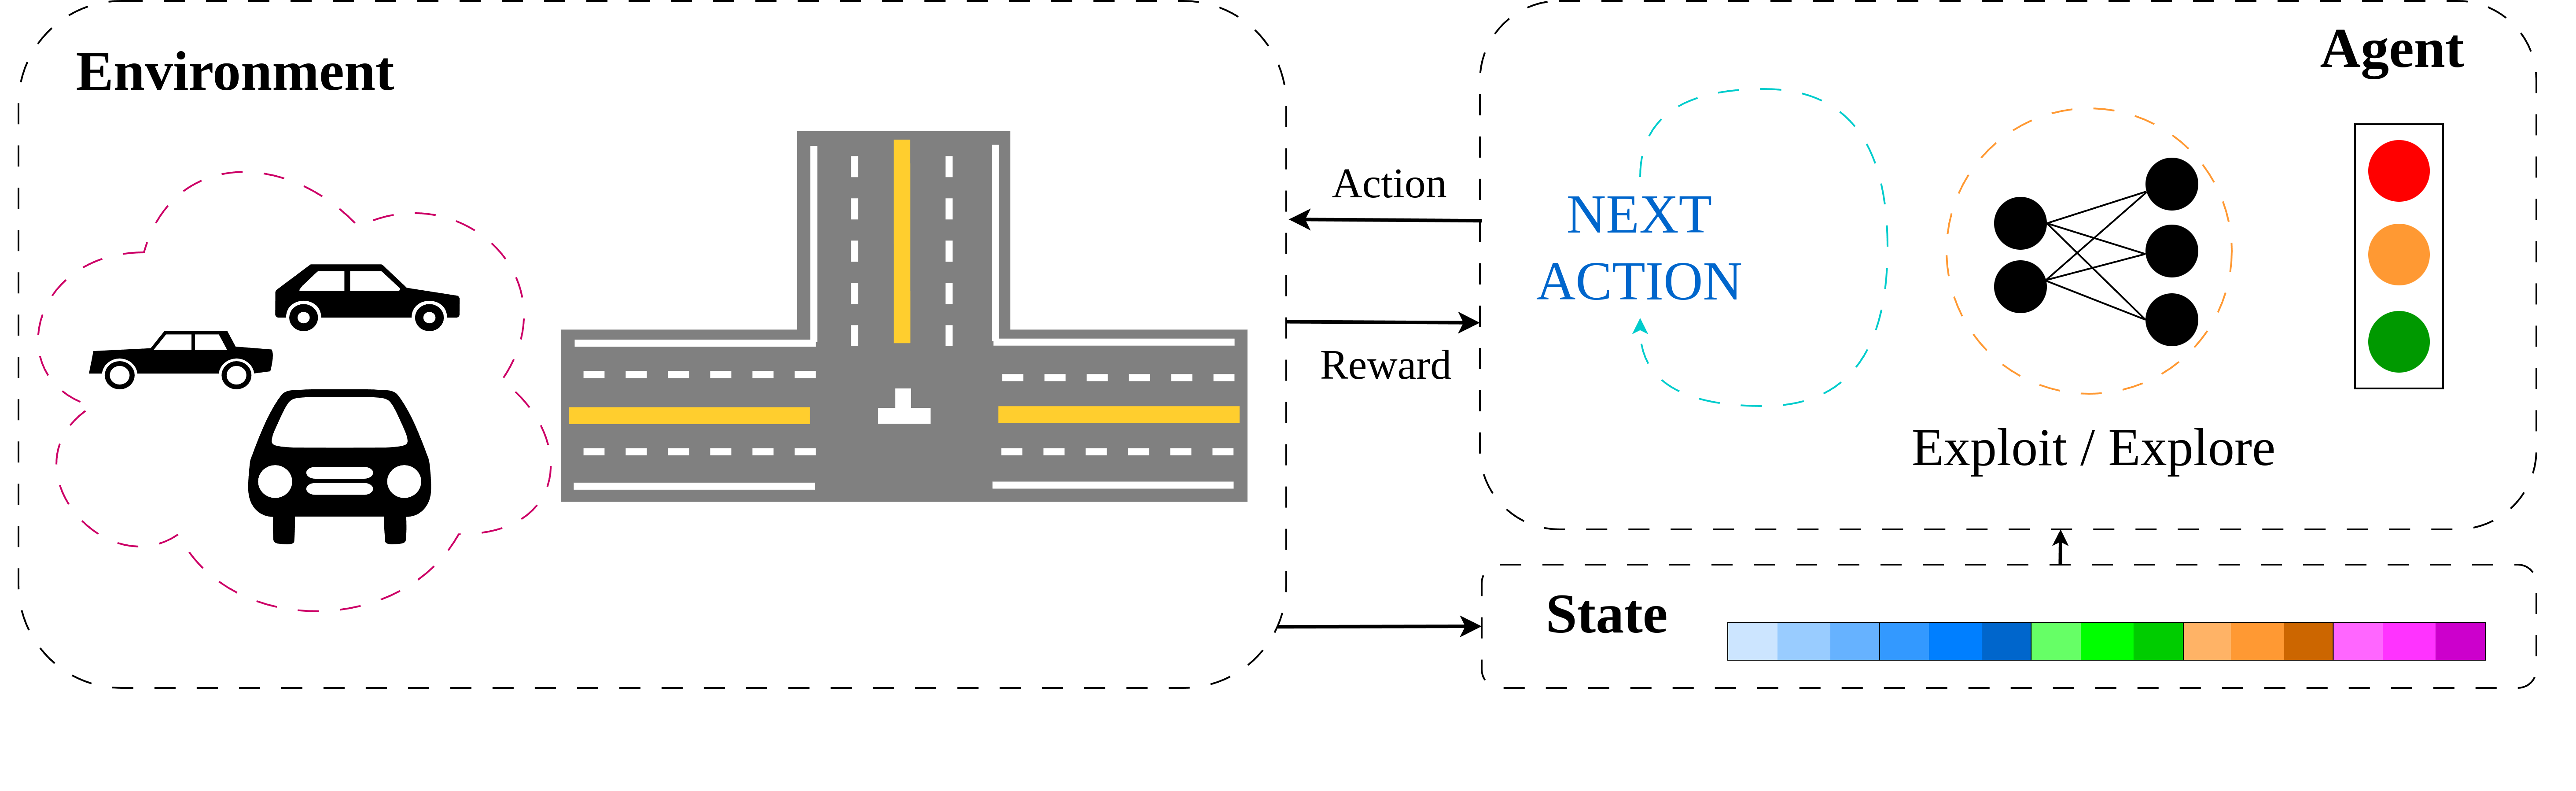
Code · Robot learning
Public Transport · 2024
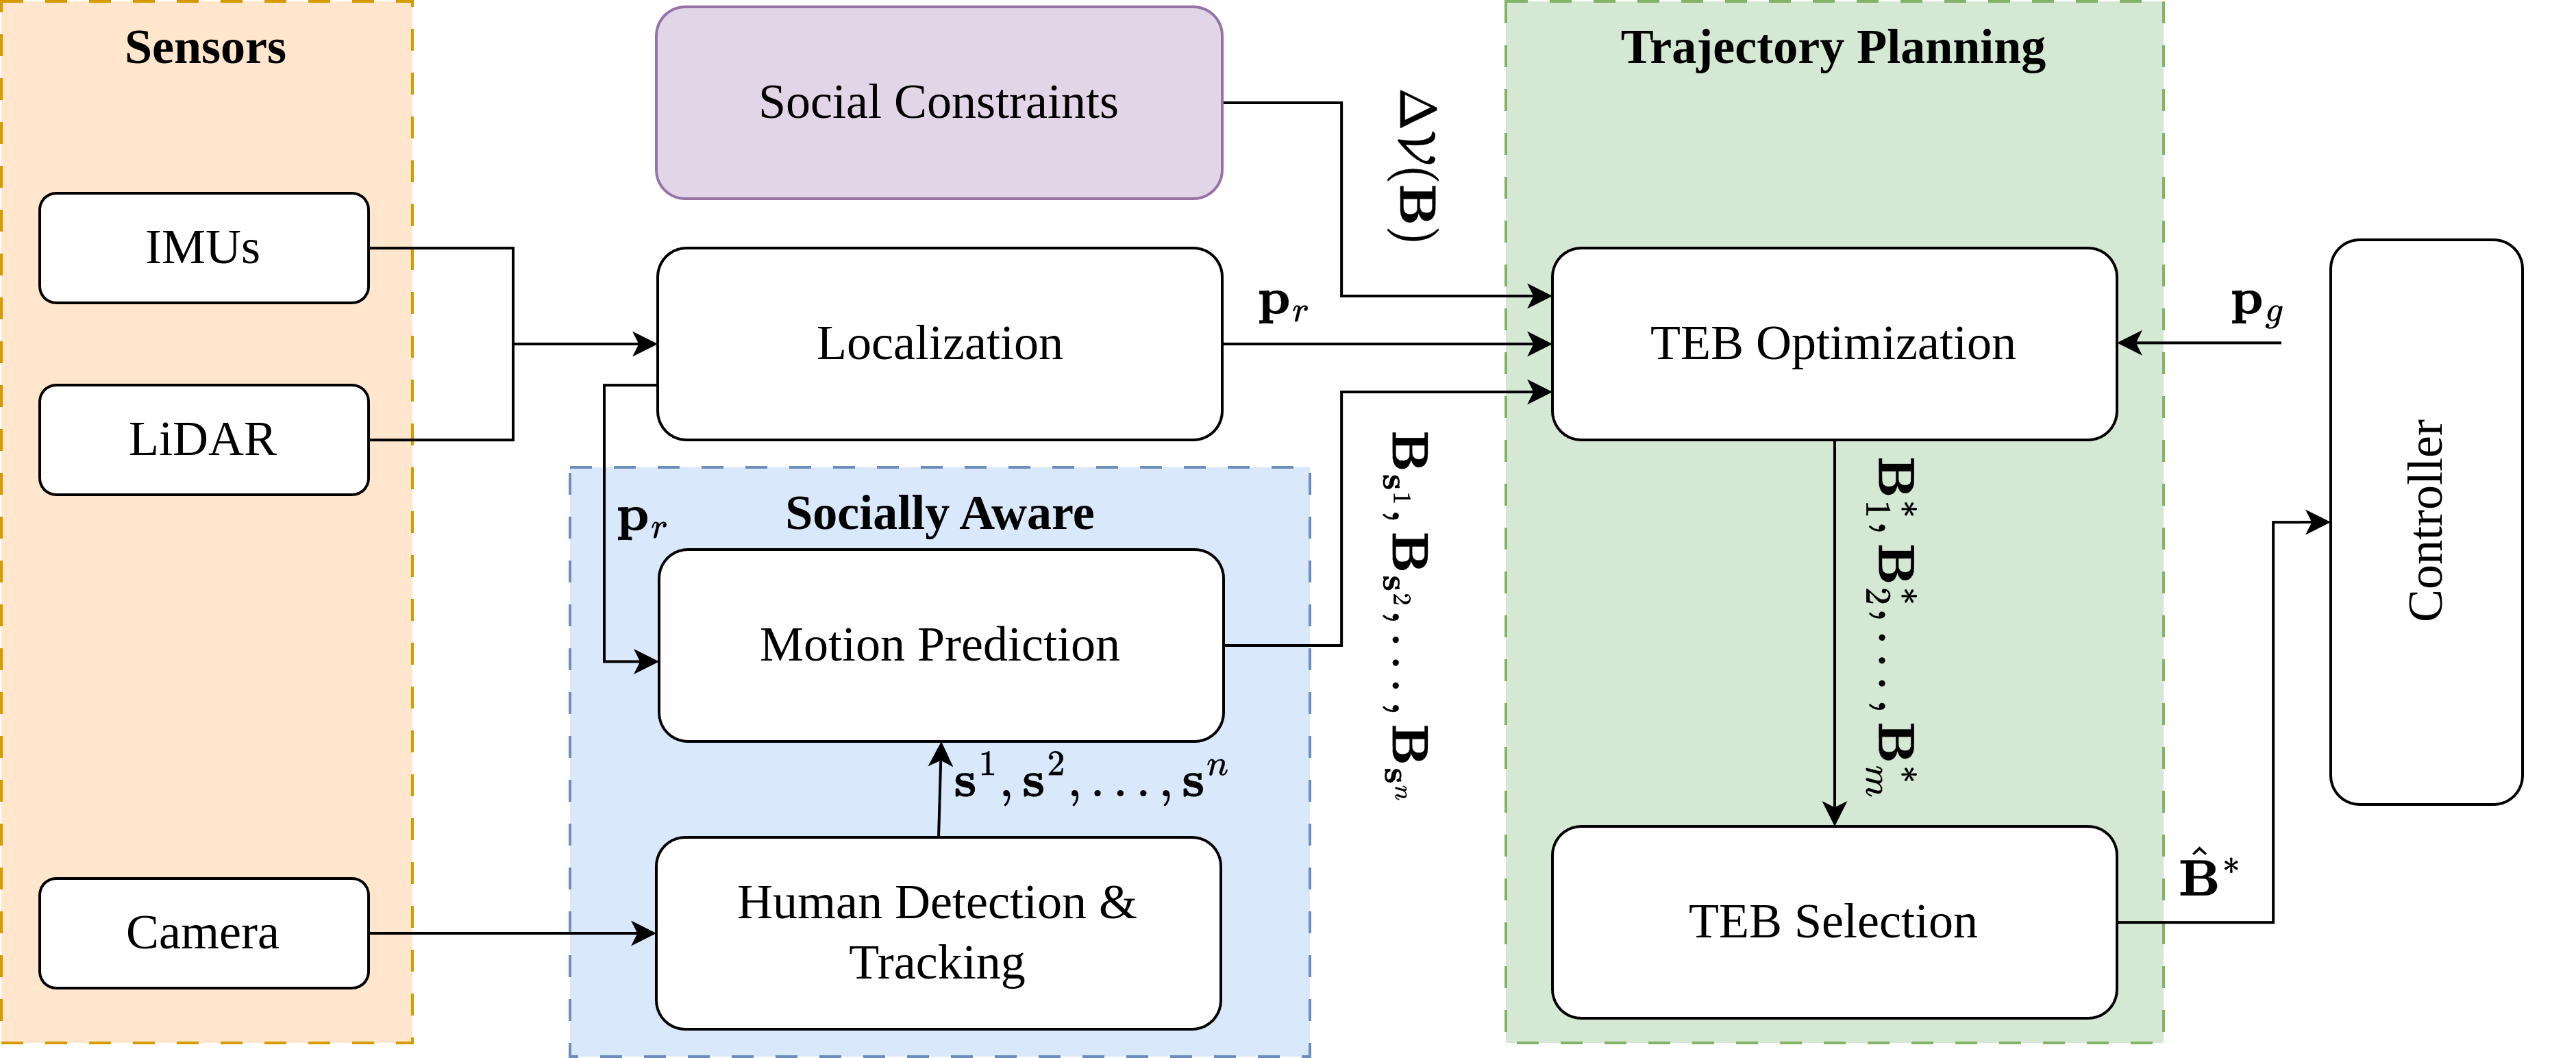
Code · Navigation
International Conference on Control, Automation and Systems (ICCAS) · 2024
Code · Semantic SLAM
IEEE International Conference on Control, Automation and Information Sciences (ICCAIS) · 2023
Code · Machine learning
IEEE International Conference on Research, Innovation and Vision for the Future (RIVF) · 2023
Dataset download links will be listed here when available. For resources associated with an existing paper, see its project page and repository.
Ask about research data ↗Please consult each repository for its license, usage instructions and citation information.